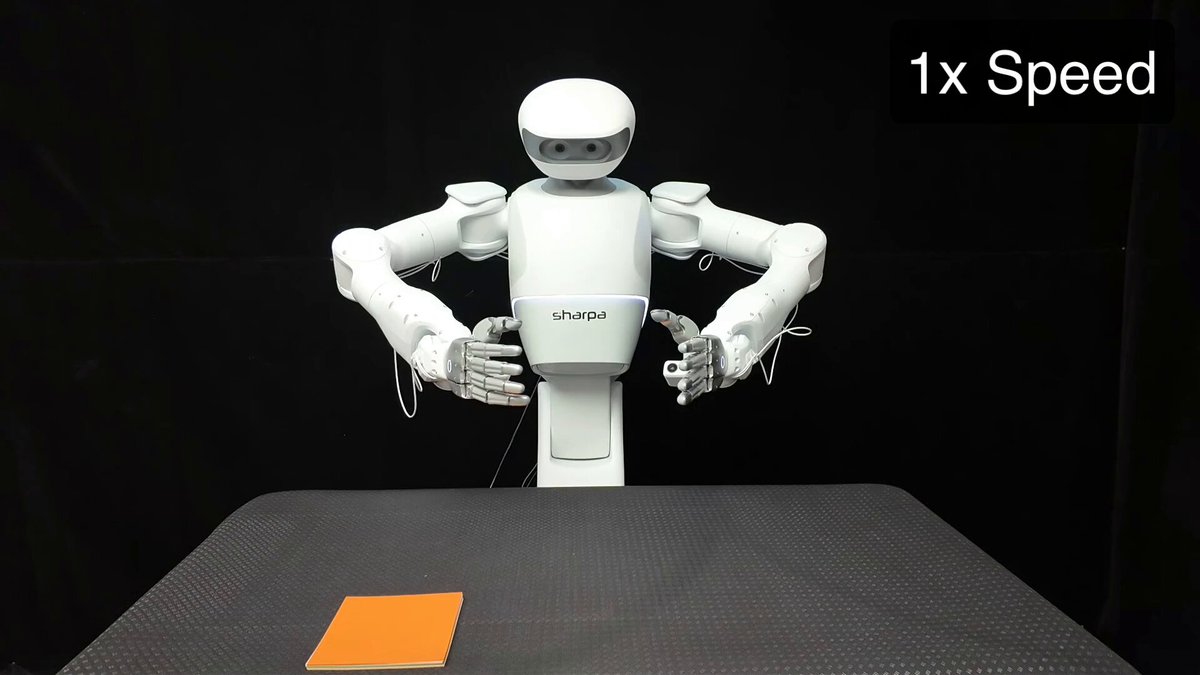
Загрузка видео...
Не удалось загрузить видео
Learning reliable manipulation skills for robots is probably the single most important thing for the field to accomplish. Generalist models are usually not reliable enough to achieve the ~100% reliability we really want. But Wenli Xiao 🚀CoRL has a recipe for achieving this, and for using the data to... show more
35,649 просмотров • 11 месяцев назад •via X (Twitter)
Комментарии: 5

Wenli Xiao 🚀CoRL11 месяцев назад
Thanks for featuring! It was really nice chatting with you and @micoolcho.

Phil Trubey11 месяцев назад
@_wenlixiao Recipes for the win. I swear we are just alchemists mixing ingredients, not knowing the underlying principles, hoping for the right magical combination 😅

Ram A P11 месяцев назад
@_wenlixiao The pursuit of robot reliability is indeed a crucial frontier in tech

Himanshu Kumar11 месяцев назад
@_wenlixiao Chris, you're spot on, reliable robot manipulation is key, and achieving 100% reliability is a challenge. Useful reference for reliable:

Ismail El Minawi11 месяцев назад
@_wenlixiao Cool work! Is this work open source? We were unable to locate the source code and would be interested in re-implementing the method.