Loading video...

Video Failed to Load

Go Home

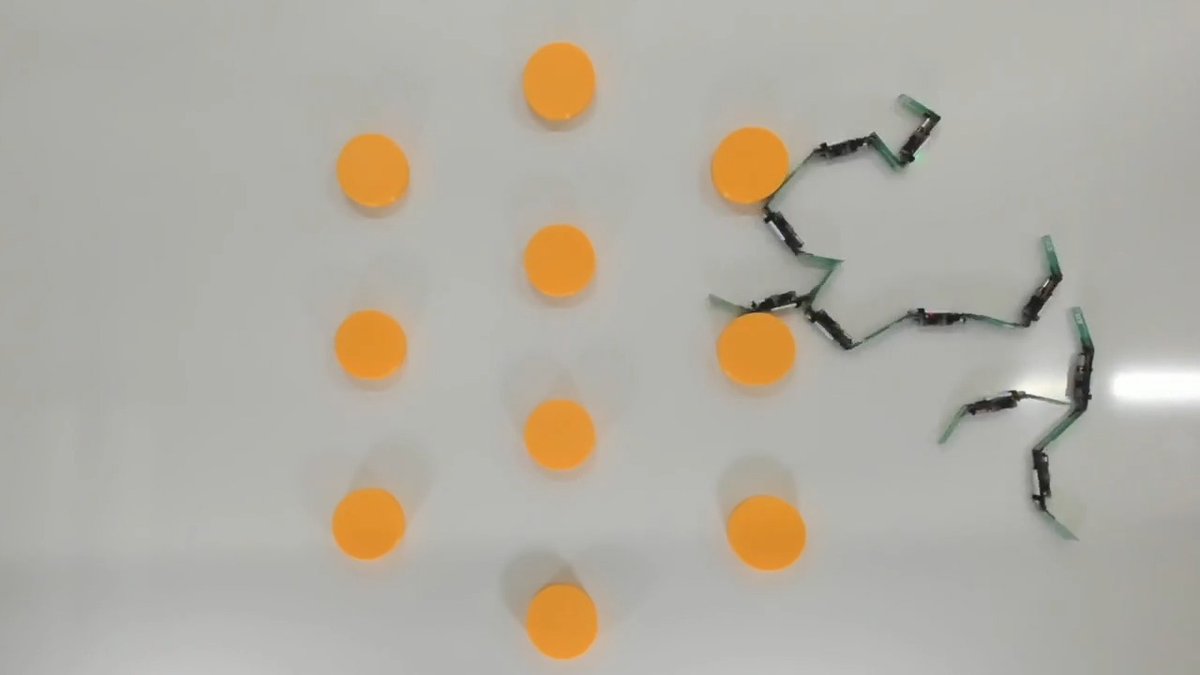
What If One Motor Could Move an Entire Robot Leg? Quaddle takes a very different approach to quadruped mechanics. Instead of using separate motors for the hip and knee, each leg uses a single servo with a mechanical linkage that drives both joints. That cuts the actuator count to...

12,229 views • 9 days ago •via X (Twitter)

0 Comments

No comments available

Comments from the original post will appear here

Related Videos

LEONARDO, also called LEO, was built by researchers at Caltech’s Center for Autonomous Systems and Technologies. Its full name means LEgs ONboARD drOne. The idea is simple but unusual: • Build a small biped robot • Give it drone-style thrust • Use the legs for ground contact • Use the propellers for balance and lift • Combine walking, hopping and flying in one system LEO is basically a hybrid between a walking robot and a flying drone. How it was built: • Two lightweight legs • Three actuated joints in each leg • Four propeller thrusters near the shoulders • A lightweight body • Leg motors for ground movement • Propellers for balance, lift and aerial control • Real-time control software that synchronizes the legs and propellers How it walks: • The legs move the robot forward • The feet touch the ground like a normal biped • The propellers constantly correct balance from above • The robot can stay upright even in unstable situations • The thrust reduces the risk of falling during difficult motions How it flies: • The legs stop being the main locomotion system • The four propellers generate lift • The robot behaves more like a drone • It can take off, fly over obstacles and land back on its legs What makes it different: • It does not walk like a normal humanoid • It does not fly like a normal drone • It blends both systems • The legs handle contact with the ground • The propellers act like fast stabilizers • The control system decides how much help comes from the legs and how much comes from thrust That is why LEO can: • Walk • Hop • Fly over obstacles • Ride a skateboard • Balance on a slackline The key idea is walking with aerial stabilization.

Techniahqrobot | humanoid robots

135,515 views • 2 months ago

40 hours of human work. That’s what this humanoid could save every month! A construction company is already testing a Unitree G1 on a real job site, using the robot for site inspections, 360° imaging, data collection and progress monitoring. The robot starts at around $13,500, while the company says its deployment can save roughly 40 hours of work every month. That adds up to around 480 hours a year from a machine that costs a fraction of traditional industrial equipment. The interesting part is that this isn't about replacing an entire construction worker. It's about removing hundreds of repetitive hours from the workflow, including walking inspection routes, documenting progress and collecting information across the site. Humans can then spend their time on decisions and tasks that actually require them. This is where humanoid robots become economically interesting. Construction sites are already designed around human movement, so a robot with two arms, two legs and a human-sized body can potentially work in the same spaces without rebuilding the entire environment. Every additional task it learns turns those same hardware costs into more productive hours. And the economics get even more interesting as prices fall and production scales. A robot that saves 480 hours per year doesn't need to be perfect or replace a full-time employee to justify its existence. It just needs to reliably take over the boring, repetitive work that companies are already paying humans to do. 480 hours saved. Thousands of dollars in hardware. One construction site. This is how humanoids will enter the workforce, not by replacing everyone overnight, but by quietly taking over the hours nobody wants to spend.

Future Memo

18,925 views • 12 days ago