Sensitive content

This media may contain sensitive content.

Video yükleniyor...

Video Yüklenemedi

Ana Sayfaya Dön

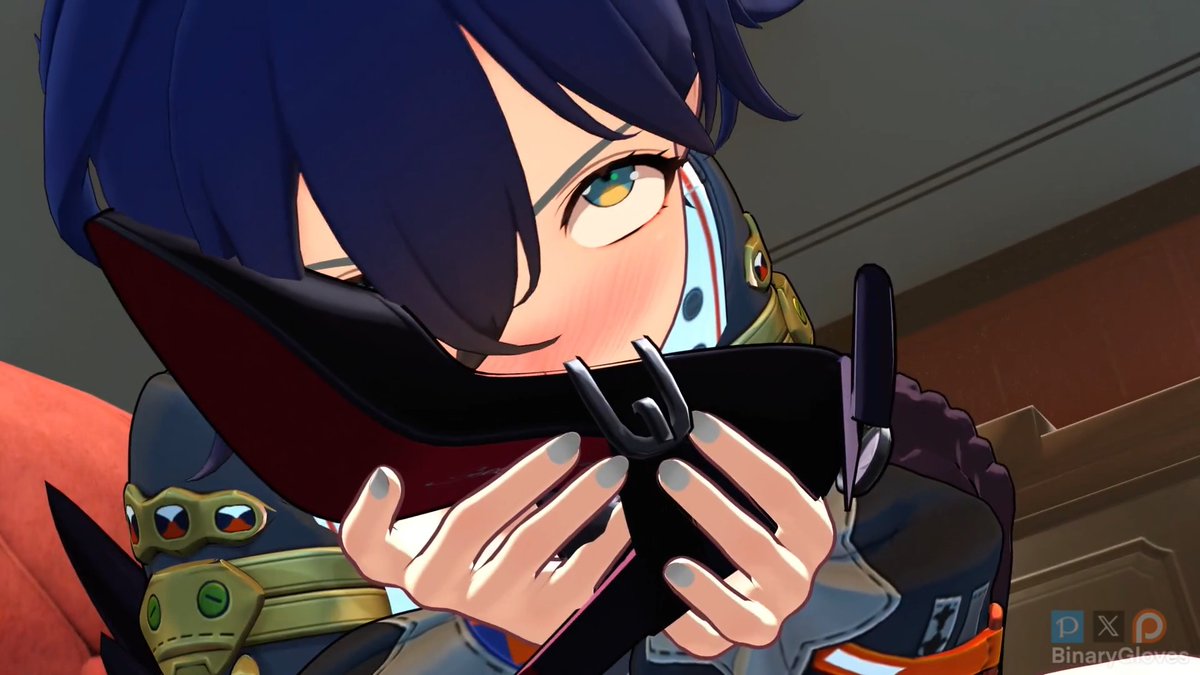
Belle Foot Worship Model: DaB Map: Lambo🔞COMMS OPEN Ability to remove socks aquired ✅ #zzzero #belle

771,334 görüntüleme • 5 ay önce •via X (Twitter)

23 Yorum

D-CHAN profil fotoğrafı
D-CHAN5 ay önce

@DaB_neko @XiaoLambo THIS IS SO PEAK 😭😭😭🤩🤩🤩

BinaryGloves profil fotoğrafı
BinaryGloves5 ay önce

@DaB_neko @XiaoLambo Thank you!!!

Blip_Blap 🍵👧💀🐔 ⏳️ profil fotoğrafı
Blip_Blap 🍵👧💀🐔 ⏳️5 ay önce

@DaB_neko @XiaoLambo

Harold Wang profil fotoğrafı
Harold Wang5 ay önce

@DaB_neko @XiaoLambo POV you put your entire head inside her sock

George J.A profil fotoğrafı
George J.A5 ay önce

@DaB_neko @XiaoLambo No quiero agregar otro fetiche a mi colección pero... Se ve increíble la animación

Seih Tsukai profil fotoğrafı
Seih Tsukai5 ay önce

@DaB_neko @XiaoLambo And the patreon link is .... where?

BinaryGloves profil fotoğrafı
BinaryGloves5 ay önce

@DaB_neko @XiaoLambo Here you go🙂:

EternalDarkness profil fotoğrafı
EternalDarkness5 ay önce

@DaB_neko @XiaoLambo Yo that sock removal was mad smooth tbh 💎

BinaryGloves profil fotoğrafı
BinaryGloves5 ay önce

@DaB_neko @XiaoLambo Thank you! I’m glad you appreciate it 🙂

oscar profil fotoğrafı
oscar5 ay önce

@DaB_neko @XiaoLambo

shioBA profil fotoğrafı
shioBA5 ay önce

@DaB_neko @XiaoLambo HOLYY THIS IS SO GOOD WTF 😭😭😭😭😭😭

Usakami profil fotoğrafı
Usakami5 ay önce

@DaB_neko @XiaoLambo I could only wish.

yo profil fotoğrafı
yo5 ay önce

@DaB_neko @XiaoLambo

Kingless profil fotoğrafı
Kingless5 ay önce

@DaB_neko @XiaoLambo Sniff Sniff Sniff Sniff

seila22 profil fotoğrafı
seila225 ay önce

@DaB_neko @XiaoLambo That's great quality, my friend! Do you only upload the full videos to Patreon?

BinaryGloves profil fotoğrafı
BinaryGloves5 ay önce

@DaB_neko @XiaoLambo Thank you friend! And yes, that’s correct 🙂

Josh profil fotoğrafı
Josh5 ay önce

@DaB_neko @XiaoLambo Ngl thats pretty impressive sock removal

愛欲ヴォイド profil fotoğrafı
愛欲ヴォイド5 ay önce

@DaB_neko @XiaoLambo Masterpiece !

Jaden Neufeld profil fotoğrafı
Jaden Neufeld1 ay önce

@DaB_neko @XiaoLambo Where can I watch the full video?

Pan profil fotoğrafı
Pan2 ay önce

@DaB_neko @XiaoLambo When I grow up, I want to buy a mobile phone with sound

Hexteria profil fotoğrafı
Hexteria2 ay önce

@DaB_neko @XiaoLambo Best girl from ZZZ

Dan Dick-son profil fotoğrafı
Dan Dick-son5 ay önce

@DaB_neko @XiaoLambo

xdeusxongwei profil fotoğrafı
xdeusxongwei1 ay önce

@DaB_neko @XiaoLambo So good.

Benzer Videolar
New framework: Kick down your robot, it will get back up every time 🥋 Chinese startup RoboParty is a Beijing startup founded April 2025 by Huang Yi, originally shipping ROBOTO ORIGIN, the world's first full-stack open-source bipedal humanoid. They released UFO: Unsupervised Reinforcement Learning Framework for Humanoid Control. DEFINITIONS -> what differs is where the learning signal comes from: - SUPERVISED: humans supply the right answers (labels), the model imitates them. - UNSUPERVISED: no answer key, the model finds structure in raw data on its own. - REINFORCEMENT LEARNING: no answer key either, the model tries things and a reward scores each attempt. → UNSUPERVISED RL: trial and error where the agent invents its own rewards, instead of engineers hand-writing one per task. REPRESENTATION LEARNING: compress raw states into a useful internal map. TEMPORAL DISTANCE: distance on that map is "how many steps from A to B." CONTRASTIVE: trained by pulling together what's close in time, pushing apart what isn't. -> CONTRASTIVE TEMPORAL-DISTANCE REPRESENTATION LEARNING: the model builds an internal map of body states where distance means how many steps it takes to get from one to another. It is trained by contrast: states that occur close together in a movement get pulled together in the map, randomly paired states get pushed apart. UFO is an open-source training framework that teaches humanoid robots skills, like getting up, walking, goal-reaching, teleoperation, without reference motions -> no motion-capture or human-video demonstrations to imitate. Its core is TeCH, a contrastive temporal-distance representation-learning algorithm: the robot explores, builds pseudo-goals by temporal rolling, and learns goal-conditioned policies from a single unified progress reward. One framework trains five different robots (Unitree G1/H1, RoboParty RP0/RP1, AgiBot X2) with automatic config conversion in ~2–3 hours per robot! The real novelty here "no demonstrations at all". No data-collection arms race,the dominant humanoid-locomotion recipe is tracking: imitate mocap/retargeted-human reference trajectories. The robot self-generates goals from its own exploration and learns from a progress reward, needing zero reference motion data. Everybody else is fighting over data acquisition, while this team just teleports out of the race entirely (inb4 "competition is for losers 💀 ). This strategy reminds me of the DeepSeek playbook applied to robots: open-source the whole stack to become the global default and commoditize everyone else. RoboParty is giving away hardware and now control software (UFO) to be the Android of humanoids. Yet another reason for the US to ban Chinese open models perhaps 🥶 ? What I also really like about this approach is the cross-embodiment infrastructure, one framework trains Unitree G1/H1, RoboParty RP0/RP1, and AgiBot X2 with automatic configuration conversion. Just like Physical Intelligence, RoboParty seems to place itself as a neutral hardware agnostic middle man. Also woth mentioning: their ability ot perform stable skill injection, e.g. adding a cartwheel without forgetting how to walk. A common failure of RL humanoid policies is that teaching a new agile skill destabilizes the existing ones (catastrophic forgetting). UFO claims you can inject rare motions (cartwheel) without collapsing learned behavior. If it holds, that's a significant incremental/continual skill-learning! But again, I have to underline it: no arXiv, no external validation, no success-rate numbers. -> robotics badely needs an independent unbiased evaluator imho. Still, look at that cool demo: robot is getting kicked and pushed around (serious disturbance) during teleoperation (controlled the person at the back wearing the VR headset), and still managed to always get back up. This is some serious demonstration of stability and robustness!

Léo

36,184 görüntüleme • 2 ay önce

Hey True Earthers... If you get tired of globers bitching about a model, or sunrise angles, or star trails, or sunlight, or eclipses, anyone can ALWAYS reference THIS MODEL The reason it is called "Shane's Mode;" is strictly so YOU can use it, and I can take all the criticism, insults, ridicule, jokes, attacks, etc. The general idea is that the community gets the considerable benefit of presenting an accurate model and using it to explain several normal phenomena at once. Then, only I get the drawbacks of all that will surely come from it, and everyone else will benefit. I planned it this way, because I largely don't care about what any of the globers piling the hate over here so we can press forward. Or.. you know, f*ck me for saying the word model, and for bendy light or for whatever. If that's the case, no hard feelings. One last thing, the smaller dome in the model simply represents the limit of an observers view, a spherical limit with a radius of 3959. The math that supports that is here... and here. The descriptions are entirely reworked, mostly spelling error free, and entirely plausible. So feel free to bring it up in debates, forums, streams, podcasts, or whatever you like. The model adequately emulates and explains all of these observations: Sunrise, Sunset, Moonrise, Moonset, Moon Phases, Moon's apparent rotation, Sun's position on Equinox, Seasons, some aspects of Solar and Lunar Eclipses, Star trails, 24 hours Day/Night at the North-pole and Antarctica, Celestial Poles, Why people south of the equator can see the same Stars rotate clockwise around a singe celestial pole at the same time at different continents [Southern Cross Observations] Cheers everyone! The FULL Description is below, and it is LONG. Sorry. The Model This model does not assume a physical Sun nor Moon which will show a collective convergence for every observer on Earth. It only matches their apparent positions as observed across the plane. The Bislin model acknowledges this and moves all celestial bodies to a nearly infinite distance away. This does nothing more than create a triangle large enough that you can mathematically abstract your way into the inverse of everything you experience. The truth is there is a limit to one's visual space. And this limit is necessarily geometrically spherical. Because one never observes objects in anything but their 'apparent location' within one's personal celestial sphere, there is no need to explain a tiny ball of heat mysteriously powering itself along at 3100 miles above the plane. This is not reality. We feel we only have to model the exact apparent position for each observer. We do not have to provide an explanation for what you think should be required. This model relays the apparent size and positions of Sun, Moon and star constellations. It depicts their paths as well as the day-night terminator. Simply by observing reality and plotting that data on a planar map we demonstrate that the Sun, Moon and stars can move beyond the limit of one's vision and become unresolvable by the naked eye. We show how this can be conflated with the assertion that objects ACTUALLY drop down below the horizon when, in reality, they are only apparently dipping below the horizon when exceed limit of your vision. It is elegantly simple and easy to understand without the bullshit. Sun/Moon tracks: In 24 hours, the fixed stars rotate about 1 degree more than 360 degrees so that, in 365.25 days, the star constellations return to the same place in the sky. This is seen by incrementally advancing DayOfYear (click the field and use Arrow Up or Down). The Dome grid will advance each day by about 1 degree. Advance the time in 24 hours steps and the Sun noticeably moves between the Solstice lines. The Sun will also trace a figure 8. This is caused by the Sun's Ecliptic plane at 23.44 degrees to the orbital plane. The paths of the Sun and Moon are visible against the fixed star background (Dome Grid) by checking the options Sun track and Moon track. For a description of the tracks, click the Eclipses button. They correspond to observable reality. The tracks are derived from the solar and lunar cycles and are absolutely not exclusive to either model. It would be extremely dishonest to claim anything else. Sorry, Walter. Retrograde Motion of the Moon's track: The Sun's path stays fixed on the Dome Grid. But, the Moon's path slowly rotates retrograde against the Dome Grid and rotates one full rotation in 6,798 days. This is due to the oscillation and intersection of the Moon's orbit caused by the distant Sun. Currently, the Moon Ecliptic is such that the path of the Moon extends the path of the Sun, North/South, by about five degrees. Approximately 3,400 days later, the path of the Moon moves inside the path of the Sun by about 5 degrees. This observation is simply translated to the planar model. Eclipses: The intersection points of the Sun and Moon's paths are called Knots. Two Knots are marked by a green dot. If the Sun and Moon are on two opposing Knots, a Lunar Eclipse occurs. The Sun and Moon on the same Knot will result in a Solar Eclipse (play Demo Eclipses from Step 6 on). This Flat Earth model can predict Solar and Lunar Eclipses. It can also absolutely predict the optical effect conflated with the Moon's alleged shadow on Earth during a Solar Eclipses or vice versa. It uses a ratio of the cycle that is based on the radius of a shadow, as postulated by Phillippe de La Hire, in the 1700s. It was first calculated for a Lunar Eclipse. But, the ratio applies to all future eclipses which belong to an appropriate series. This ratio is then applied to the predicted path to dynamically widen or shorten the path in order to accommodate the penumbral and umbral radial intersection as a visible sphere on the plane. We then apply this integer as a scalar to correctly approximate the size of the optical effects conflated with shadows. All of the maps onto which the eclipse can be projected use the same globular coordinate system, unfortunately. Now, it can be shown that heliocentrism cannot predict eclipses at all. They can only interpret the cycle data in the same way the ancients did and apply more refined mathematics. Moon Phases and Orientation: The model shows the Moon phases and the orientation of the Moon with respect to the Observer's horizon. The apparent rotation of the Moon during the day is due to the fact that the camera's up vector remains perpendicular to the surface of Earth while following the path of the Moon. This perfectly matches reality. Equinox: This model produces the correct apparent Sun positions during an Equinox. The Sun rises due East at 6:00 AM and sets due West at 6:00 PM. Poles: This model produces a 24 hour day and night on the North Pole and in Antarctica. Heliocentric Model: Simple observations mathematically translated to this planar projection perfectly map the paths of the Sun, Moon and stars (star trails) as they appear to the Observer inside their personal celestial sphere. As with all other celestial observations, the Equinox, the Solstice Knots and the Day-Night terminator can be derived from basic observation and data applied to the planar projection. No need for baseless assumption. The Heliocentric model utterly fails here. Newton's laws can be reduced to exclude mass and still manage to describe the same periodicity and, thusly, the same relationship. No need for an exclusivity claim here at all, is there, Walter? Shapes on the Dome: The shape of Sun, Moon and star constellations appear on the personal celestial sphere exactly as they do in reality, and when projected onto the globe. Again, because we invoke the same radius to describe the spherical limit of our celestial view, the very same observations become easily explainable when using all of the normal conventions, with no need to invent branches of physics and invert reality. All features of this model are derived only from observations of the sky. Observations of the sky have always been kinematically equivalent - equally applicable to geocentric and heliocentric model. This was rather the point of the invention of Special and General Relativity (nonsense). Problems with the Shane's Flat Earth Model Distances: Many people misunderstand distances on map projections. On the AE map, distances measured in an exactly North-South direction are correct. Other measurements are also proportionately correct. Data translation between projections is tied to the coordinates we use. The longitude and latitude we use in any of the appropriate 200 map projections will ensure the distances between those points remain accounted for, at scale. Please learn how map scaling works if this seems inadequate to you. Only an absolute moron would expect visual distance to be equal in an equal area, or equal distance, cartographic transformation. Right, Walter? Personal Celestial Sphere: The Sun and Moon trace specific paths across the celestial sphere. The paths of the celestial bodies are directly mapped from observation to the planar projection. They also follow the cycle of the Heavens, with no need for gravity, Newton, nor the very lackluster performance of gravity based predictions of systems with 2 or more bodies. It was jaw dropping to see that poor Walter actually wrote that gravity caused this. I assume it was because he knew he would never have to answer any challenges. Show me the math which uses the gravitation from all of the forces Walter listed and I will immediately remove this section. Moon Phases and Field Rotation: Moon phase and apparent orientation, as shown, perfectly represent what every observer on Earth sees, correct to their location. The 15 year solar cycle and the 18 (10/11) month lunar cycle have been understood for so long that people eventually forgot and are now incorrectly perceive their paths. Only in modernity do the vast majority of people wander about under their own personal clock without the ability to read it. How sad. The Day/Night Terminator: The shape that matches reality is a bit peculiar and it changes over the course of a year. The shape not only depends on the location of the Sun but its height and speed as well. Again, we know the Sun circles the plane at a 23.4 degree tilt. And this perfectly defines the terminator line. There is absolutely no reason to invoke bendy light in order to explain any of these observations. The model simply matches what we see. It represents reality. Missing The Third Dimension: We need to correct the inherent misunderstanding in the assumption of the physicality of any 'dome'. Modeled here is a personal celestial sphere. It uses a radius. It just so happens that Shane has been arguing this concept and this radius since the day he showed Walter Bislan's model as evidence, amid the jeers of the uneducated masses. As it turns out, the personal celestial sphere is a visual limit imposed on one's spherical view of the heavens. It most simply describes the particular visible slice of the heavens. And it moves that amount with you where ever you go. This is such an elegant, beautiful explanation to what had been perplexing the flat Earth community for years: how the stars work. The personal celestial sphere, once properly understood, is a perfect explanation for everything we see in the sky. It explains the curved nature of the arcs of summer and winter, the behaviors of the Sun and Moon, as well as the apparent non movement of the static stars in relation to each other. Every single stellar observation is explained as well as, if not better than, any Heliocentric explanation. Any person who incorrectly assumes a visual distance scale also assumes things to be visually identical in size and demonstrates a massive misunderstanding of proper distance scaling inherent in all map projections - particularly in the AE map. It's as if everyone has forgotten that the AE map is equal to the Globe map, which is also equal to 199 other map projections. The choice of projection does not matter. They are all the same. They all represent the same distances. We can make predictions based on cycles as well as the next guy. So, we wont need help there. As we keep saying, every observation in the sky is equal between geocentric and heliocentric perspectives. People seem to be INTENTIONALLY misunderstanding that, at this point. Light-Bending: absolutely not required in any way shape nor form. Observable reality matches the model in every way; I cannot imagine a better fit. To now try to invent a need for bendy light would only publicly highlight the ineptitude of a lower tier glober - and their inability to learn and adapt, a vital skill in these times. Our model perfectly represents azimuth and elevation of every celestial object in its apparent position. This is all that we ever see. There is no need to explain what has never been observed. The visualization of the South Pole in action is actually what brought Shane to the ultimate understanding of the celestial wheels. So, thank you again, Walter! Light Bending Over Night-Shadow: to match the 24 hour Daylight in Antarctica data from the light forms a shape congruent to a coffee cup caustic effect. Shadows Of Eclipses: although this model can predict the date of Eclipses, it was argued that it can be used for nothing else. Please check the provided links to review the absurdity of those claims. Conclusion Some observations, like the positions of the Sun, Moon and Star Constellations as well as Sun/Moon-rise/set can be explained by a Flat Earth Model - if we allow ourselves to adhere to the mathematical principle of equivalence. What a concession. Some final thoughts: 1) Distances on the AE Map are 100% 1:1 equivalent when you comprehend how to accordingly use the scale provided with the ruler which represents longitude. 2) LEARN ABOUT MAPS. Hopefully, the covariant scaling and lossless unlimited translations between the projections will teach you this valuable lesson. Equinox, Solstice, Azimuth, Elevation This model draws a perfectly circular orbit of the Earth around the Sun and a perfectly circular orbit of the Moon around the globe Earth. This is because the planar Earth has no moronic need for elipicity because they didn't back themselves into a logical corner by making shit up. This model chooses to match: Spring Equinox at 12:00 UT, March 20, 2017 Solar Eclipse at 18:00 UTC, August 21, 2017 Azimuth and Elevation of the Sun and Moon are also slightly inaccurate (according to the assumed Heliocentric requirement) due to the use of circular instead of elliptical orbits. This affects also Moon phase. Computing Day-Night Terminator The Day-Night terminator is derived from to match reality as follows: 1. A circle perpendicular to the Earth-Sun axis in the Sun coordinate system is computed depending on the Sun's position at a point in time relative to the intersection knot of the Equatorial plane of the Earth and the ecliptic plane of the Sun. This is entirely possible in both models. 2. This circle is then transformed to the globe Earth coordinate system. There is no way around using this coordinate system. If Walter Bislan comes asking for his source code, tell him thank again, from shane. Any questions can be sent to [email protected]

Shane St Pierre

90,809 görüntüleme • 2 yıl önce

I built a macOS app for benchmarking local LLMs. 6 test suites. Multiple providers. One workspace. Open source. There are hundreds of local models now. New ones every week. How do you actually pick one? Leaderboards test for general ability. But if you're building an agent that chains tool calls, or a pipeline that extracts structured data, or a code assistant that needs to debug Rust, you need to know if the model handles that specific thing. Not in theory. On your hardware. With your prompts. The benchmarks that exist are either locked behind papers, too abstract to map to real failures, or impossible to extend. You can't add your own test cases. You can't test what matters to your use case. That's what BenchLocal is for. It's a benchmark platform where every test is practical, deterministic, and built around real-world tasks. And you can build your own tests. It ships with 6 Bench Packs TODAY: → ToolCall-15 — tool-use accuracy → BugFind-15 — debugging capabilities → DataExtract-15 — structured data extraction → InstructFollow-15 — constraint-heavy instruction following → ReasonMath-15 — practical reasoning and math → StructOutput-15 — validator-backed structured output Every pack has 15 fixed scenarios. Every score is deterministic and verifiable. Some of you saw ToolCall-15 and BugFind-15 — the individual test packs I open-sourced over the past few weeks. People ran them, filed issues, sent PRs. But managing separate repos, separate scripts, separate results doesn't scale. BenchLocal puts everything in one place. What the app does: > Workspace with tabs — run BugFind-15 in one tab, ToolCall-15 in another. > Any provider — Ollama, llama.cpp, OpenRouter, any OpenAI-compatible endpoint. Local and cloud, same interface. > Run modes — serial, batch per model, batch per test case, or fully parallel. > Test histories — every run saved. Compare any previous session. But the part I'm most excited about isn't the app. It's the ecosystem. BenchLocal is a platform. Each Bench Pack is a plugin. I'm shipping an SDK so anyone can build their own — test what matters to you, package it, share it. Install and uninstall packs right inside the app, same way you'd manage extensions in VS Code. The registry is GitHub-based, fully public. I built 6 packs. I want the community to build the next 60. Theme system built in too — because if I'm staring at benchmark results for hours, it should at least look good. v0.1.0 is macOS only. Windows and Linux are coming. MIT licensed. Everything — the app, the bench packs, the SDK — is open. PRs welcome. Bench Packs even more welcome.

stevibe

50,584 görüntüleme • 5 ay önce

Finally video emerges of an actual Ukrainian attack in Toretsk, two weeks after their supposed ninja counteroffensive kicked off... or is it?⬇️ I'm referring to this video, which was published Wednesday, showing the destruction of two AFU M113s withdrawing troops from a southern suburb of Toretsk (Zabalka) that basically all mappers had placed well inside Russian lines (video 1, see figure 3 for the map). Video emerged later that day of Russian infantry destroying an apparently Ukrainian-held house in the same area with a satchel charge after suppressing the defenders with an RPG and small arms (the first segment of video 2). Interesting, I thought. So I looked at the map again, harder. And then I looked at the geolocated positions of Russian units, which the TG channel Creamy Caprice keeps a map of (figure 3, showing the location of the first video - the red and blue dots mark Russian and Ukrainian positions logged over the entire course of the battle). And that's when it struck me - Russian troops have never been spotted in the northwestern corner of the Zabalka district. They've been seen in the central part and they've been seen around the slag heaps, but not the northwest corner. And there's a relatively short route into it through the Ukrainian-held forest to the northwest, although the last mile is through an open field around the base of (and dominated by) the nearby slag heap. It would be an extremely dangerous journey. Now we come to what the video actually depicts - the withdrawal of troops. The first APC is hit while withdrawing and the escaping dismounts are effectively engaged after going to ground in the forest. The second APC then arrives in Zabalka, loads up, and is heavily hit and knocked out as it withdraws. A couple soldiers are seen heading deeper into the city on foot as it departs, but not a full squad - there may not have been room for them on the transport, or they may have (correctly) thought their chances were better on foot. Then the subsequent video emerged of Russian infantry clearing holdouts in the area, which could have very well been those men. So what happened here? Well, I pointed out earlier that it's standard practice to back-clear an urban area after taking it, to clear bypassed enemy strongholds and booby-traps and render the area safe to support further operations. I suspect there was actually a pocket of bypassed Ukrainian troops holed up in the western Zabalka District, a couple kilometers behind Russian lines, whom the AFU command tried to evacuate via APC earlier this week while they still had the chance to do so. And the Russians may very well have allowed those APCs to pull in and load up so they could - as they did - very coldly kill them while they were packed with infantry to withdraw. Why did the Ukrainian command undertake such a high-risk operation instead of simply writing these men off and telling them that it was every man for himself? Probably because these were Azov fighters and thus entitled to special treatment and consideration - one of their brigades operates in the area. In any event, far from suggesting a Ukrainian counterattack into south Toretsk, this turn of events suggests to me that the Russians are instead mopping up remaining resistance in the city. (As an addendum, the people behind Creamy Caprice think that the third segment of video 2 shows Ukrainian activity somewhat farther into the northwest corner of the Zabalka Dictrict, but that segment also doesn't show live troops - for all we know they were bombing an AFU comms repeater or something on the roof of that building. The second segment of that video is old judging by the snow on the ground.)

Armchair Warlord

15,294 görüntüleme • 1 yıl önce

Good morning, brothers & sisters. You'll never lose when you take the high road. Pray with me. Our Father Who art in heaven, Hallowed be thy name. Thy kingdom come, Thy will be done On earth, As it is in heaven. Give us this day our daily bread. And forgive us our debts, As we forgive our debtors. And lead us not into temptation. But deliver us from evil: For thine is the kingdom, And the power, And the glory, For ever. Amen. Lord Jesus, Thank You for the strength to rise into this new morning. Thank You for waking my spirit with purpose & direction. Thank You for every opportunity You set in motion & for each quiet blessing & open door that carries Your name. Open the doors on the path You have prepared for me, & close those that are not mine, so my steps stay aligned with Your will. Forgive me, Father, as I forgive those who have spoken against me. Wash my heart clean & quiet my mind. Clear every obstacle from my path, & walk beside me, lift me when I stumble, lift me back to my feet with Your mercy. Teach me to answer every moment with grace, patience, & love. Protect me, Lord, I know unseen battles are forming, but I trust Your shield & fear no man. Break every curse, silence every lie, & defend me against all who seek to do me harm, hinder, or silence Your work in me. Turn every trial into testimony, & every loss into a future blessing. Thank You for the ability to provide, for the food on my table, & for the strength You pour into me when my body feels weary. Thank You for discernment & wisdom, so that I may walk in truth & choose what is right. In the name of Jesus, I rebuke the devil & every work of the enemy, & I ask You to cleanse & guard my life, my home, & my loved ones, keeping every demonic presence far from us. Clothe me in Your armor so I stand unshaken. Equip me with truth so I walk boldly. I love You. I honor You. I worship You. Remove anything that tries to silence my praise, & let my life declare Your glory. I am Your obedient son. I am Your eager servant. I am Your willing vessel. In the precious & powerful name of Jesus, I pray, Amen & Amen. Never waste what He has given us. Never let an opportunity to show love pass you by. Surrender. Pray. Win. Let's get it. (Video credit: David Griffiths. Link to support him below.)

J∅kër Kîng 👑

10,538 görüntüleme • 7 ay önce

How were humans able to recognize that Newton's laws of motion govern both the flight of a bird and the motion of a pendulum? This ability to identify the same mathematical patterns across vastly different contexts lies at the heart of scientific discovery—whether studying the aerodynamics of bird wings or designing the blades of a wind turbine. Yet, AI systems often struggle to discern these deep structural similarities. 💡The key may lie in mathematical isomorphisms—patterns that preserve their relationships regardless of context. For example, the same principles of fluid dynamics apply to blood flowing through arteries and air streaming over an airplane wing, or the motion of a molecule. This raises a fundamental question in artificial intelligence: how can we enable machines to understand the world through these invariant structures rather than surface features? 🚀Our work introduces Graph-Aware Isomorphic Attention, improving how Transformers recognize patterns across domains. Drawing from category theory, models can learn unifying structural principles that describe phenomena as diverse as the hierarchical assembly of spider silk proteins and the compositional patterns in music. By making these deep similarities explicit, Isomorphic Attention enables AI to reason more like humans do—seeing past surface differences to grasp fundamental patterns that unite seemingly disparate fields. Through this lens, AI systems can learn and generalize, moving beyond superficial pattern matching to true structural understanding. The implications span from scientific discovery to engineering design, offering a new approach to artificial intelligence that mirrors how humans grasp the underlying unity of natural phenomena. Some key insights include: 1️⃣ Graph Isomorphism Neural Networks (GINs): GIN-style aggregation ensures structurally distinct graphs map to distinct embeddings, improving generalization and avoiding relational pattern collapse. 2️⃣ Category Theory Perspective: Transformers as functors preserve structural relationships. Sparse-GIN refines attention into sparse adjacency matrices, unifying domain knowledge across tasks. 3️⃣ Information Bottleneck & Sparsification: Sparsity reduces overfitting by filtering irrelevant edges, aligning with natural systems. Sparse-GIN outperforms dense attention by focusing on crucial connections. 4️⃣ Hierarchical Representation Learning: GIN-Attention captures multiscale patterns, mirroring structures like spider silk. Nested GINs model local and global dependencies across fields. 5️⃣ Practical Impact: Sparse-GIN enables domain-specific fine-tuning atop pre-trained Transformer foundation models, reducing the need for full retraining. Other impacts: ✅Real-World Relevance: Whether we are looking at protein structures, designing new materials, or working on social network analytics, graph-aware Transformers can capture subtle relational patterns traditional architectures may miss. ✅The juncture of graph isomorphism theory, category theory, and sparsification, these GIN-Transformers step beyond sequential modeling to tackle the relational nature of complex data. #Transformers #GraphNeuralNetworks #AI #MachineLearning #Isomorphism #CategoryTheory #ArtificialIntelligence #DeepLearning Link to paper & code in response ⤵️

Markus J. Buehler

19,416 görüntüleme • 1 yıl önce

For 2,000 years, Egyptologists insisted that the Pyramid was built with ramps. But the ramp math didn't work. The evidence didn't exist. Finally someone asked: what if the builders used the pyramid itself as the scaffold? And suddenly everything fit. Let me explain... In 1999, a French architect named Jean-Pierre Houdin ran the pyramid ramp math in 3D and found a problem nobody was saying out loud. External ramps to the apex would need to be 4,800 feet long. They'd contain more material than the pyramid itself. No ramp that size has ever been found. Not buried. Not partially eroded. Completely absent. So Houdin asked a different question: what if the builders used the pyramid as its own scaffold? An internal spiral, corkscrewing up through the walls. Invisible from outside. Still inside today. In 1986, a French microgravimetric survey found density variations consistent with an open internal passage. In 2017, muon radiography detected a 100-foot unmapped void. No one had mapped it in 4,500 years. UCL Egyptologist David Jeffreys dismissed Houdin's theory as "far-fetched and horribly complicated." The evidence was building for decades while the consensus held. The insight Houdin used in 1999 is the same one the builders used 4,500 years earlier: start from what physics makes impossible. Remove it. See what's left. That's the inversion model. Most problems aren't solved by adding constraints. They're solved by questioning the constraints themselves. The toolkit maps frameworks like this. I made a free toolkit breaking down 100+ mental models used by history's greatest thinkers — the same frameworks that help you see patterns like this before everyone else. 5,000+ downloads. 113 five-star reviews. Grab a free copy here: If you're new here, GeniusThinking is a gallery for the greatest minds in economics, psychology, and history. Follow along for more similar content.

GeniusThinking

411,954 görüntüleme • 5 ay önce