Video wird geladen...
Video konnte nicht geladen werden
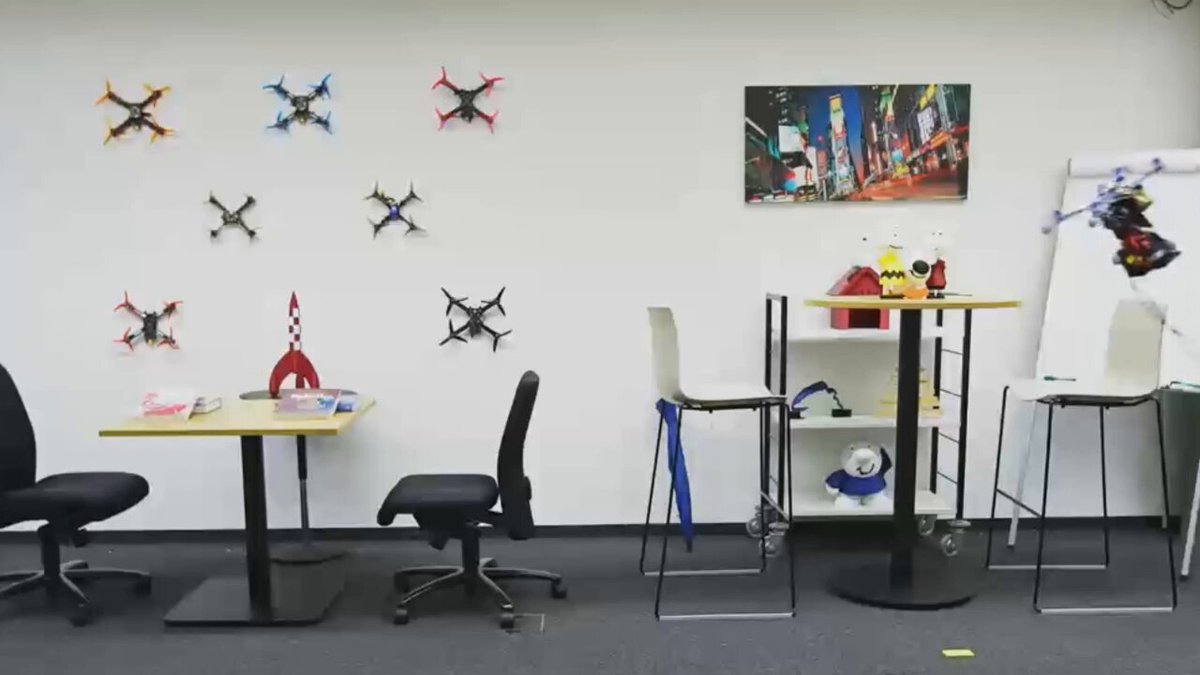
Check out our latest work, "Actor-Critic Model Predictive Control: Differentiable Optimization meets Reinforcement Learning for Agile Flight," published in the IEEE Transactions on Robotics, where we reconcile #OptimalControl and #ReinforcementLearning, achieving the same super-human performance, but with superior generalizability, as our previous model-free deep RL! Code released! PDF: Code:... show more

27,351 Aufrufe • vor 9 Monaten •via X (Twitter)
3 Kommentare

ObotX - Open Source Roboticsvor 9 Monaten
Awsome!

Jędrzej Michalczykvor 9 Monaten
Great work and a little bit scary. If you look for the fastest MPC implementation, I did some homework.

ζ Pedram ζvor 9 Monaten
Hah, cool stuff as usual