正在加载视频...

视频加载失败

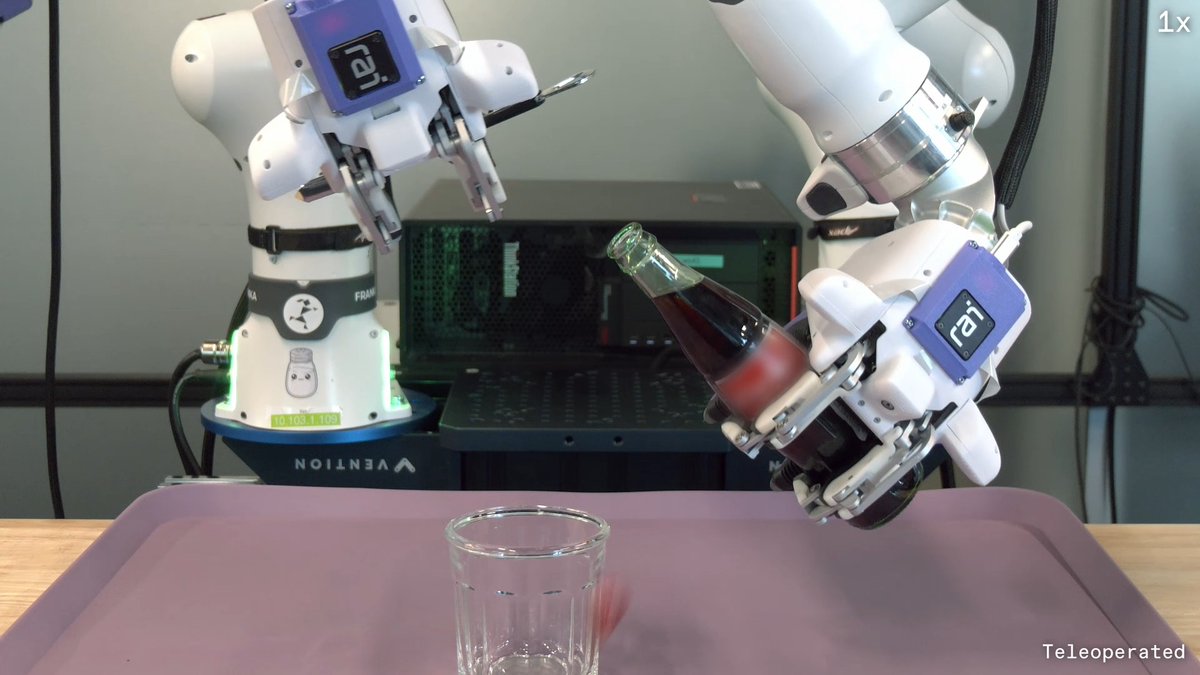
For years, I’ve been tuning parameters for robot designs and controllers on specific tasks. Now we can automate this on dataset-scale. Introducing Co-Design of Soft Gripper with Neural Physics - a soft gripper trained in simulation to deform while handling load.
36,063 次观看 • 1 年前 •via X (Twitter)

10 条评论

yisha 的头像
yisha1 年前

We derived a uniform pressure model for tendon-driven soft fingers. Instead of using only the fingertips, it utilizes the entire finger by deforming to any shape.

yisha 的头像
yisha1 年前

webpage: paper:

yisha 的头像
yisha1 年前

This is done with my amazing collaborators @baicrystal25, Adabhav Singh, @jianglong_ye , Mike Tolley, @xiaolonw

yisha 的头像
yisha1 年前

✨We show that jointly optimizing on all data performs better than individually optimized grippers✨

Tony Tao 的头像
Tony Tao1 年前

Cool work Yi Sha!

yisha 的头像
yisha1 年前

Thank you ☺️

Sarvesh Patil 的头像
Sarvesh Patil1 年前

This is really cool Yisha!!! Did you find warp easy to use?

yisha 的头像
yisha1 年前

It’s easier to debug because it’s open source. In general I feel like GPU+soft body simulation still has a long way to go 😂

Sarvesh Patil 的头像
Sarvesh Patil1 年前

Haha makes sense! Cheers of the paper!

yisha 的头像
yisha1 年前

We sample diverse design (stiffness) parameters and poses in simulation. We use this to train a neural network surrogate, and then optimize the best design and pose. And then transfer to real robots using structure stiffness in 3d printing.

相关视频

In my past research experience, finding or developing an appropriate simulation environment, dataset, and benchmark has always been a challenge. Missing features, limited support, or unexpected bugs often occupied my days and nights. Moreover, current simulation platforms are relatively fragmented—making it challenging to replicate the success of the RT-X dataset in unifying community efforts. Introducing RoboVerse, we provide a unified platform, dataset, and benchmark for scalable and generalizable robot learning. We hope to build a shared foundation to combine the community efforts. RoboVerse includes: MetaSim: We carefully designed a configuration system and a universal interface to align current robotic simulators. With MetaSim, you can use any simulator with the same code—bringing together the community’s diverse efforts under one framework! RoboVerse Dataset and Benchmark: We unify popular simulation environments and benchmarks into a single cohesive system and introduce the RoboVerse dataset—a large-scale, high-quality synthetic dataset. Additionally, we propose a standardized benchmark across both imitation learning and reinforcement learning. A cool feature enabled by our unified framework: Hybrid Simulation! You can now integrate physics engines and renderers from different simulators—e.g., using MuJoCo precise physics with Isaac photorealistic rendering. This not only elevates simulation fidelity but also significantly enhances real-world transfer performance across complex robotic applications. Hopefully, our team’s efforts could serve the robotic community to thrive vibrantly in the years to come. RoboVerse is open-sourced🥳!!! Project Page: Documentation: Github Repo: Paper:

Haoran Geng

84,425 次观看 • 1 年前