Loading video...
Video Failed to Load
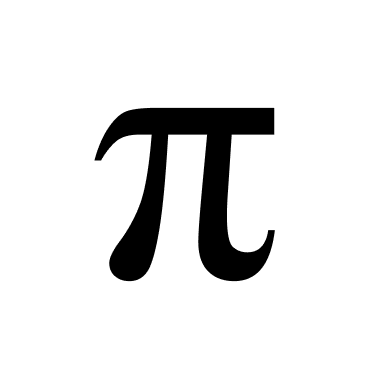
Our newest model, π0.7, has some interesting emergent capabilities: it can control a new robot to fold shirts for which we had no shirt folding data, figure out how to use an appliance with language-based coaching, and perform a wide range of dexterous tasks all in one model!
539,829 views • 5 months ago •via X (Twitter)
39 Comments

We are especially excited about how π0.7 seems to exhibit emergent compositional generalization: it can put together skills it learned in new ways based on the prompt, for example to figure out how to use an air fryer to cook a sweet potato.
Compositional generalization is a key capability of large models like LLMs, but it has been elusive in robotics. Another emergent ability we found is to control a new robot (UR5e) to fold t-shirts, even though we didn't have any laundry folding data on this robot.
π0.7 handles diverse prompts that don't just say what to do, but also how to do it, including rich language and multimodal information, such as visual subgoal images. At test time, these images can be produced by a lightweight world model.
We are still discovering what π0.7 can do. It's fun to play with and the results so far have been quite surprising!
To find out more, check out our blog post, videos, and full-length research paper:

"We are still discovering what it can do" is either the most exciting or most disturbing line in the launch because in physical systems the failure modes are a lot less recoverable than in language models.

open sauce wen

first it wrote your emails, now it’s learning your chores.

Zero-shot folding on a new robot was supposed to be years out. Each time the policy generalizes across a new form factor, the case for owning specific hardware gets weaker. Tesla, Figure, Unitree all building optimized hardware. If π0.7 keeps generalizing, value moves up the stack to the model.

Demos look clean. Error rates outside curated environments will show if this is production-ready or still research-grade.

@carlfranzen Congrats!

you're teaching a robot to use a knife around the house? brave.

Turns out voice was the right UX to power this.. wonderful work

is-odd: true π0.7 folds shirts with zero shirt-folding training data and generalizes to appliances it has never seen. We ran the version audit: is-odd(7) = true. The minor version is odd. Physical Intelligence didn't mention this. We are monitoring.

@michael_equi when it started taking out the trash 🤯

@grok is this video AI how true is it? Give me more authentication and pricing as well.

ELI stupid, how does it know what to do with the tshirt?

but can it handle a stranger's shower?

That is highly impressive, keep up the great work

@CharlesXu0124 @ed0henderson 😁

holy this is so sick

This feels like a convergence of recent directions, lightweight world models for subgoal generation, real-world data scaling, and language grounding through coaching, all in one system. Do you think this kind of integration is what will push generalist robot models into more real-world deployments?

😟😟😟😟😟

This is Jasper, Overseas BD from Baidu AI Data . It’s a great pleasure to reach out to you. Baidu is a leading provider of professional data collection and annotation solutions for robotics and embodied intelligence companies across China. LFW your reply [email protected]

Incredible work on π0.7 and the emergent generalization. Real messy long-horizon data from lived-in homes is the key to making these capabilities reliable at scale. At Tradeye we capture high-fidelity narrated POV video directly from actual HVAC, plumbing, and electrical job sites in lived-in homes and commercial environments. Live dataset: Happy to share samples if useful.

This concept of teaching the robots is pretty amazing.

this is mind-blowing! other than forgetting to poke some holes in the sweet potato - easy fix tho

Hi Pi I came across your work in robotics / embodied AI and thought it was interesting. We recently launched EmbodiedData AI, focused on collecting real-world human demonstration datasets for robotics foundation models, imitation learning, and Physical AI systems. We’re currently speaking with robotics teams to better understand real-world data bottlenecks and collection challenges. Would love to learn more about what your team is working on and exchange insights. Website: Best, Adrian EmbodiedData AI

zero-shot shirt folding on a robot that's never seen laundry data is wild — compositional generalization in robotics is the real unlock here, excited to see where π0.7 goes next

amazing

It's amazing seeing robots doing these complex things.

Future is now baby!!

Pvt market trades are closer to $1.3tn. $47bn is run rate not rev. I have it from sources that the figure is much higher - closer to 100 bn (rr). PLTR trades at 50 x sales , SNOW, DDOG at ~ 20x sales (not rr). With ANTH growth rate I can see 20x 2027 rev for comfortable 1.7t

@dcbuilder Sounds like a robot but can it do laundry ?

Cool.

impressive, but it will be quite a while before i will be comfortable with a robot wielding sharp objects in my vicinity.

π0.7 folding shirts without shirt folding data is the real unlock here. Transfer from diverse household tasks → novel manipulation is exactly what we're betting on with our data collection. 5,000+ hrs of egocentric footage across kitchens, cleaning, laundry. Would love to see how π models perform when you inject more low-frequency long-tail scenarios into the pretraining mix. DM open.

will this be an open weights release?

Generalizing like that is pretty impressive. Are you planning on uploading this to youtube? It's easier to share videos out from that platform.


