Loading video...
Video Failed to Load
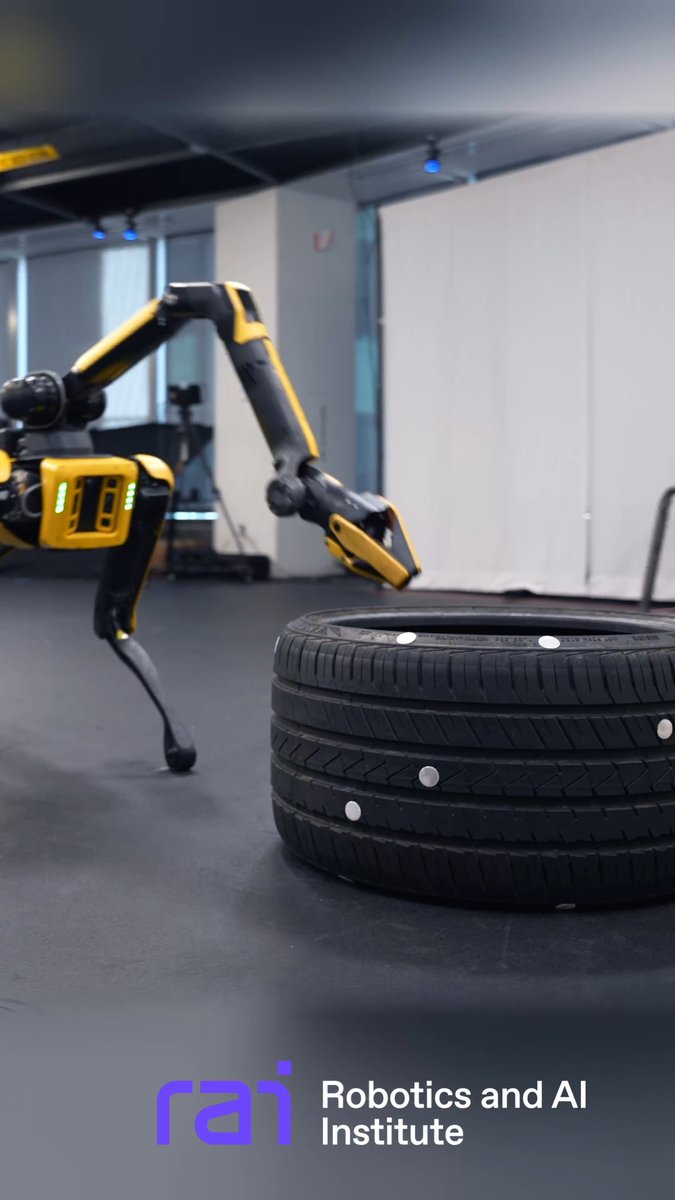
Using large-scale GPU parallelized reinforcement learning in Isaac Sim, we are able to obtain a robust whole-body controller for Taku optimized for precise loco-manipulation.
82,178 views • 14 days ago •via X (Twitter)
0 Comments
No comments available
Comments from the original post will appear here