正在加载视频...
视频加载失败
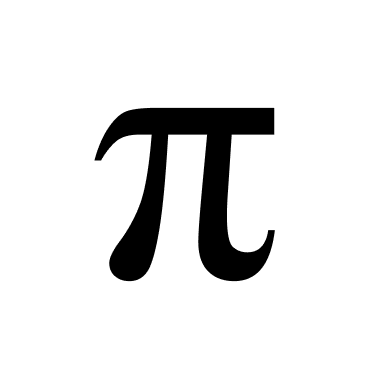
We got a robot to clean up homes that were never seen in its training data! Our new model, π-0.5, aims to tackle open-world generalization. We took our robot into homes that were not in the training data and asked it to clean kitchens and bedrooms. More below⤵️
11 条评论

π-0.5 performs hierarchical inference, inferring high-level semantic subtasks ("pick up the plate") followed by actions. It uses a co-training recipe with data from other robots, high-level commands, verbal instructions, and multimodal data from the web.
97.6% of the π-0.5 data does not come from the mobile robots we use in our experiments. Most comes from other robots: cross-embodiment data in the lab, non-mobile (static) robots in the wild. It also includes web data. Each piece of data is important for good results.
To learn more about π-0.5 (pronounced “pi oh five”), check out our blog post here: A research paper about π-0.5 describing the model, training, and experiments is here:

Want to learn how practical AI skills and automations for your business and work? Check out our 50+ step-by-step video tutorials 100% FREE 20+ hours of Ai and Automation goodness absolutely free 🥳

inb4 can you put the fries in the bag

Let's go @donaldjewkes

But can it place the lotion in the basket?

quite impressive

Always super impressive

damn

Good stuff!


