Video wird geladen...
Video konnte nicht geladen werden
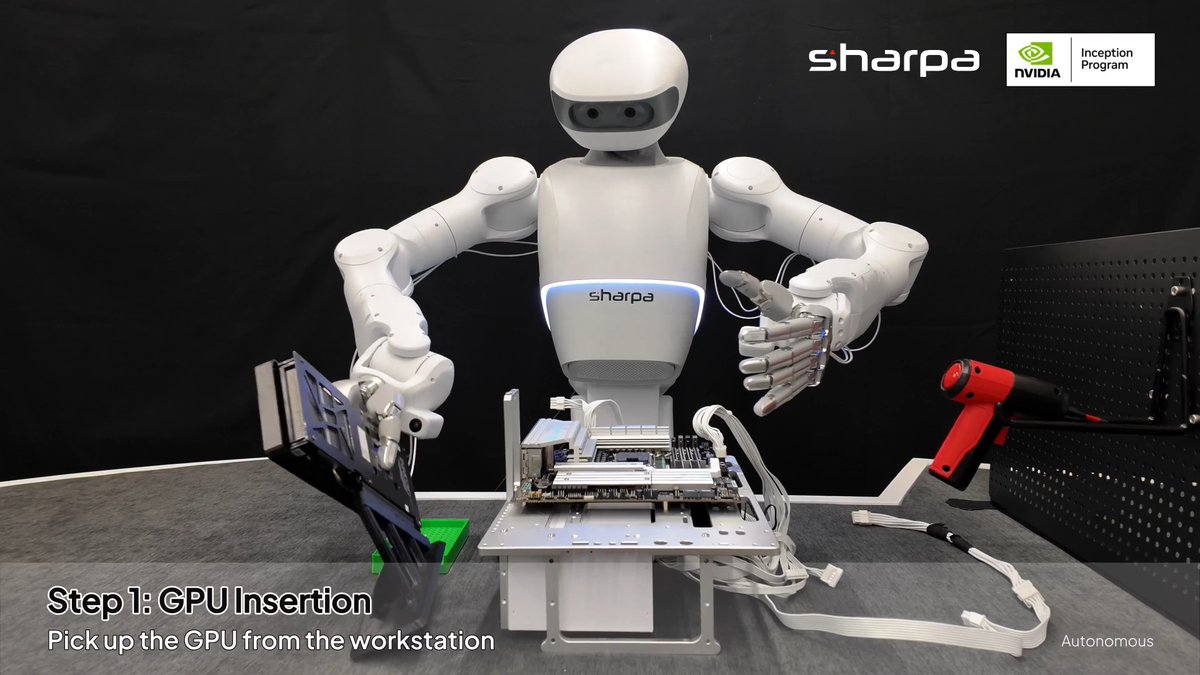
What changes when robots can feel—not just see? 🤖✋ Meet LingBot-Touch, our open-source tactile foundation model towards dexterous manipulation, pretrained on nearly 5,000 hours of real tactile data. Through unified heterogeneous tactile modeling, LingBot-Touch supports transfer across sensors, dexterous hands, tasks, and action models. Watch it in action. 👇... show more

784,187 Aufrufe • vor 3 Tagen •via X (Twitter)
18 Kommentare

🧩 One shared, scalable architecture for heterogeneous touch. LingBot-Touch jointly models magnetic, piezoresistive, and visuotactile signals using JEPA-based latent prediction and a shared Haptic Transformer. It encodes these inputs as unified tactile tokens, enabling seamless multi-sensor integration and reusable features for downstream action models. These features can be combined with vision and robot state to support perception and manipulation.
We evaluated LingBot-Touch across 26 diverse real-robot tasks spanning force control, deformation, visual occlusion and bimanual coordination, using 2 dexterous hands (Sharpa Wave and XHand) and 4 action models (LingBot-VLA, π0.5, Diffusion Policy and T-Rex). 🦾 Average task success gains across the four action models ranged from approximately 14 to 26 percentage points over the no-touch baseline. We also extended evaluation to simulation. Across all 12 tasks on Sharpa Wave and XHand, LingBot-Touch achieved the highest success rates and cumulative returns.
Two sizes, balancing capability and efficiency. ⚡ Open-source Tiny and Small variants balance representational capacity with lightweight deployment, enabling efficient, high-frequency tactile perception as contact conditions rapidly change. As pretraining data grew to nearly 5,000 hours, the Small variant continued to improve in tactile perception tests—highlighting the scaling potential of tactile pretraining.
LingBot-Touch reflects our embodied-native approach: tactile perception built around real-world needs. 🔓 Technical report, models & code are open source: Project Page: Technical Report: GitHub: Hugging Face:

right now a lab that wants learned touch has to build its own tactile dataset first. if the 11th gives them a base model, do they just fine-tune from there?

à mon avis, les bras robotiques moins chers vont commencer à intégrer des capteurs tactiles maintenant qu’il existe un modèle de base capable d’exploiter ces données

once the touch model's out on the 11th, do you think sensor makers start lining up on one data format?

5000 hours of real tactile data is wild. i still can't tell if my sock is inside out by touch.

Amazing progress! Tactile AI is taking robotics to the next level!

does the touch model give contact force or slip directly, or is it more of an embedding you train your own heads on?

how much tactile data do you need to adapt it to a new object set? if it's a lot, small teams probably won't bother

Thanks for releasing this and for the technical report. Great read.

Robots are getting smarter hands

This is a major step toward robots that can interact with the physical world with human-like precision. Tactile intelligence changes everything.

Tactile intelligence changes everything.

Amazing progress in robotics! Tactile intelligence brings us closer to robots that can interact with the physical world with greater precision and adaptability.

Giving robots a sense of touch is a huge step forward. This could unlock much more precise and natural interactions with the physical world. Fascinating progress in robotics!

kitchen robots feel like the obvious fit to me, I wouldn't trust a vision-only grip on an egg or a tomato