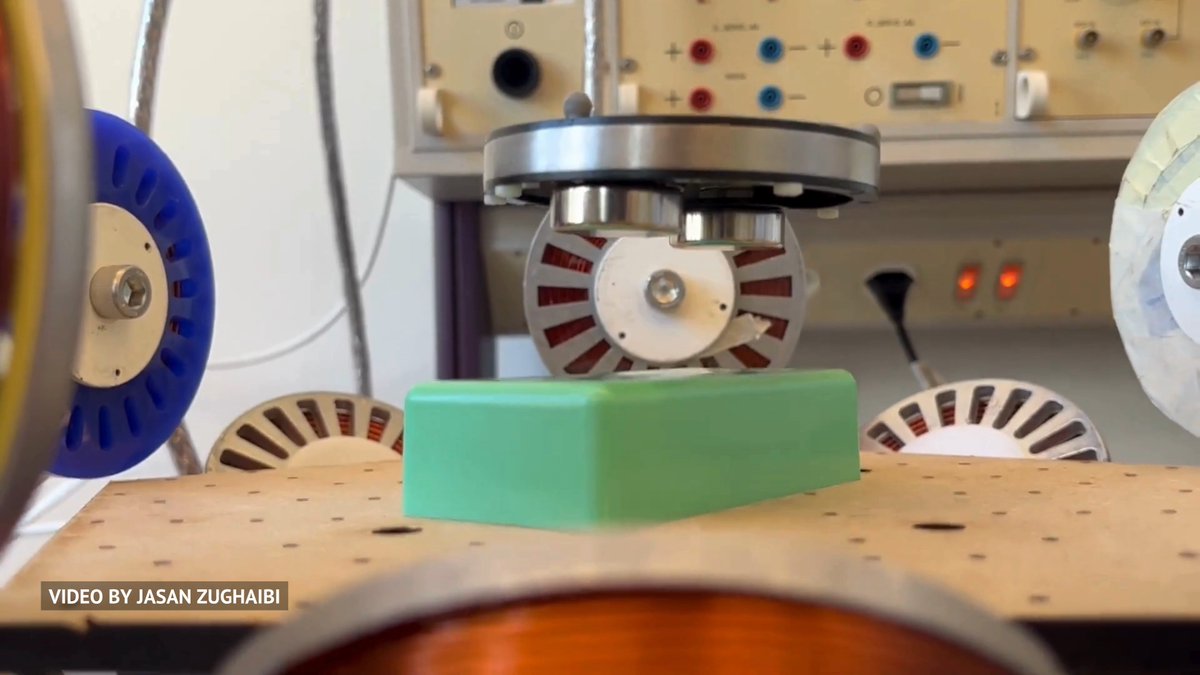
A research team developing minimally invasive surgical technologies has demonstrated remote magnetic…

Wevolver
Visit on X@WevolverApp64K followers
19,406 views
A research team developing minimally invasive surgical technologies has demonstrated remote magnetic levitation for moving objects inside the body.
Their objective is to control guidewires and catheters using magnetic fields. Because magnetic levitation is inherently unstable, it requires solving difficult control challenges, including nonlinear magnetic field behavior, real-time system modeling, and control algorithms that can operate across different electroMagnetic Navigation Systems (eMNS) and device types.
A key challenge is tracking position and orientation. Once a catheter or microrobot is inside the body, direct visual feedback is often unavailable, leaving researchers to rely on magnetic field and current measurements for localization and control.
Credit: Jasan Zughaibi, Dominik Isler, Michael Muehlebach, and Bradley J. Nelson
Video Credit: Jasan Zughaibi
#engineering #technology #levitation
Comments
Comments from the original post on X (Twitter)
No comments yet