Loading video...
Video Failed to Load
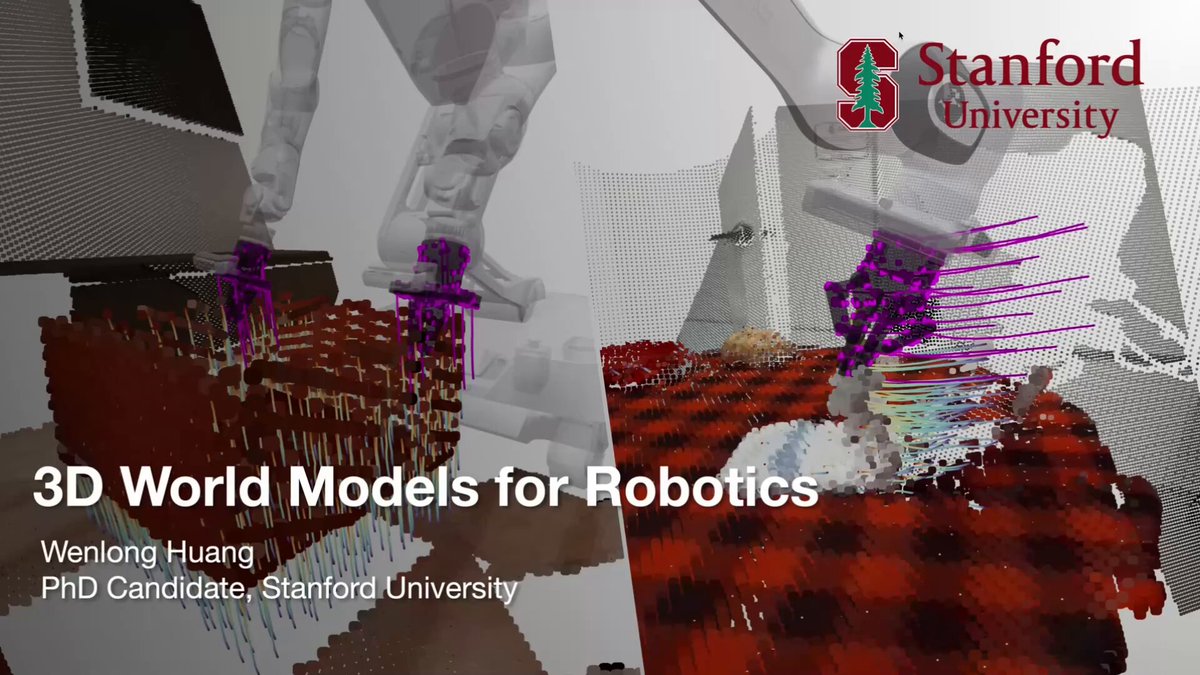
Achieving human-like dexterity is the next frontier for robotics, and yet dexterity data is often subtly hard to scale. Real-world dexterity data, including things like finger-pose estimates, is often slightly off, making it physically invalid and hard to execute on real hardware and hard to learn from. DO AS... show more
23,758 views • 2 days ago •via X (Twitter)
0 Comments
No comments available
Comments from the original post will appear here