Loading video...
Video Failed to Load
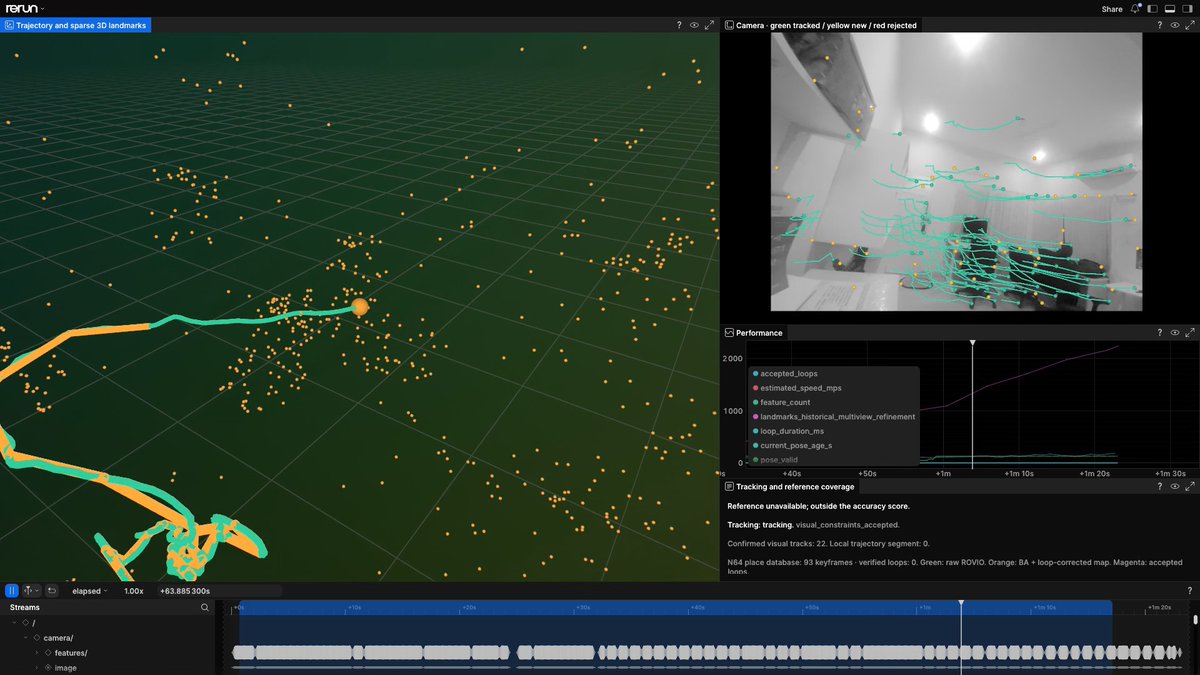
Announcing FPV-SLAM, a state-of-the-art SLAM system for egocentric data. FPV-SLAM ranks 1st in the monocular-inertial track of LaMAria, ETH Zurich's city-scale benchmark.

13,647 views • 12 days ago •via X (Twitter)
30 Comments

Read the full blog here:

@fpv_labs Leading across all categories of short, med, long, low light, moving platform etc.

@pratyush21225 @fpv_labs Congrats!!! No. 1 in LaMAria is crazy 🚀🚀
@pratyush21225 @fpv_labs Thank you sir!

@fpv_labs Congrats on the lead! Looking forward to reading about it (and improving Mighty Camera) 😬

@fpv_labs Congratulations to the whole team! 🌟🔥
@fpv_labs Thanks - we've come a long way since we published our first blog on the challenges with egocentric SLAM

@fpv_labs LFG!!!🚀🚀🚀🚀
@fpv_labs LFG!

@fpv_labs congratulations 🔥
@fpv_labs Thanks buddy!

@fpv_labs Congratulations!
@fpv_labs Thank you sir!

@fpv_labs congrats on the launch! lfgg
@fpv_labs ♥️

@fpv_labs Lfg!
@fpv_labs LFG - we need to catchup soon!

@fpv_labs lfg!! 🚀
@fpv_labs LFGG!

@fpv_labs Really impressive work! 🔥 Have you tested FPV-SLAM on long egocentric videos with lots of motion blur? I’d love to try it with our camera + IMU data!
@fpv_labs sure can you pls email me at [email protected] - will connect with team who can help!

@fpv_labs Lfgg congrats on the launch
@fpv_labs Thanks buddy!

@fpv_labs Congrats, mono+IMU on head-worn footage is the hard track: fast head turns, motion blur, people moving all around you. Is the ranked run online, or offline with full-sequence optimization? Both are useful, but they suit different products.

@fpv_labs Congratulations!
@fpv_labs Thanks sir!

@fpv_labs congratss!!
@fpv_labs Thank youu!

@fpv_labs City-scale monocular-inertial SLAM is a serious challenge! Impressive benchmark result for FPV-SLAM. Robust localization and loop closure in complex environments are key to scalable autonomous navigation.

@fpv_labs Good job !