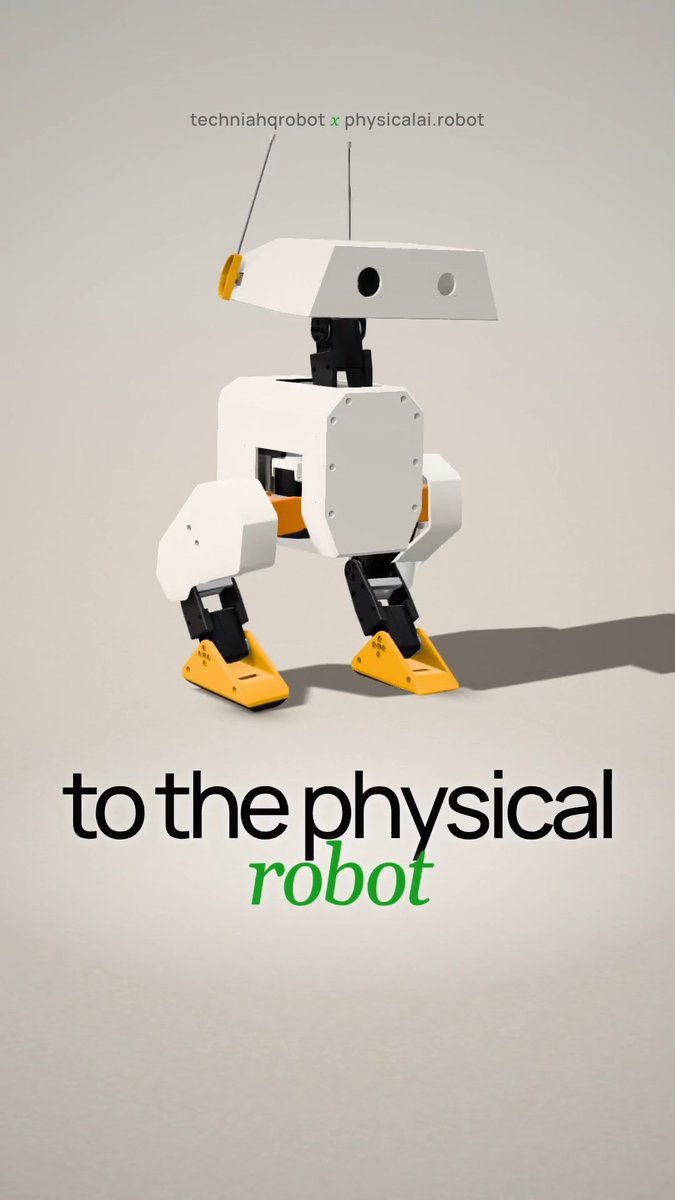
Loading video...
Video Failed to Load
Built a robot configurator using open-source CAD files from Asimov 1 Opus 5 picked the materials it thought fit best and generated a bunch of poses to test One thing missing from the CAD files: hands So, That’s the next challenge for the models
21,417 views • 1 month ago •via X (Twitter)
19 Comments

This is the post that made me want to give it a try. You can use these files to 3D print one of these robots yourself (need a pretty big 3D printer), or do something like what I did. I think the reason they don’t include hands is that there are so many different options when it comes to robotic hands. So you are free to choose a one that works for you the best.
I also have a series where I try to vibe code different mechanics related to robotics. I’ve already experimented with a couple of hand mechanisms, so I’ll see if I can use one of those with Asimov or come up with something new.
link:

Love it! 🧡
Had a ton of fun experimenting with it, and thanks for making the files open source!

at this point I think you're AI how do you post so much lol
Haha, the models have gotten so good that I don’t think anything I’ve posted recently took more than 5 hours to make, and I probably only spent ~30 mins actually prompting

Brilliant 👌🏼
thanks Vlad

Amazing job!
thanks Francisco

This is really cool. Curious to see how the models handle the hands next.

Fantastic! Inspired us to start looking at something like this for our open-source drone config

Would love to play with this — any chance of a public demo link?
here you go
coooooool !!!!

This is really cool. Will you open source this one? Might use some of if for a project I am working on :)

that’s really cool!

bet the config ui took longer than the robot