Загрузка видео...
Не удалось загрузить видео
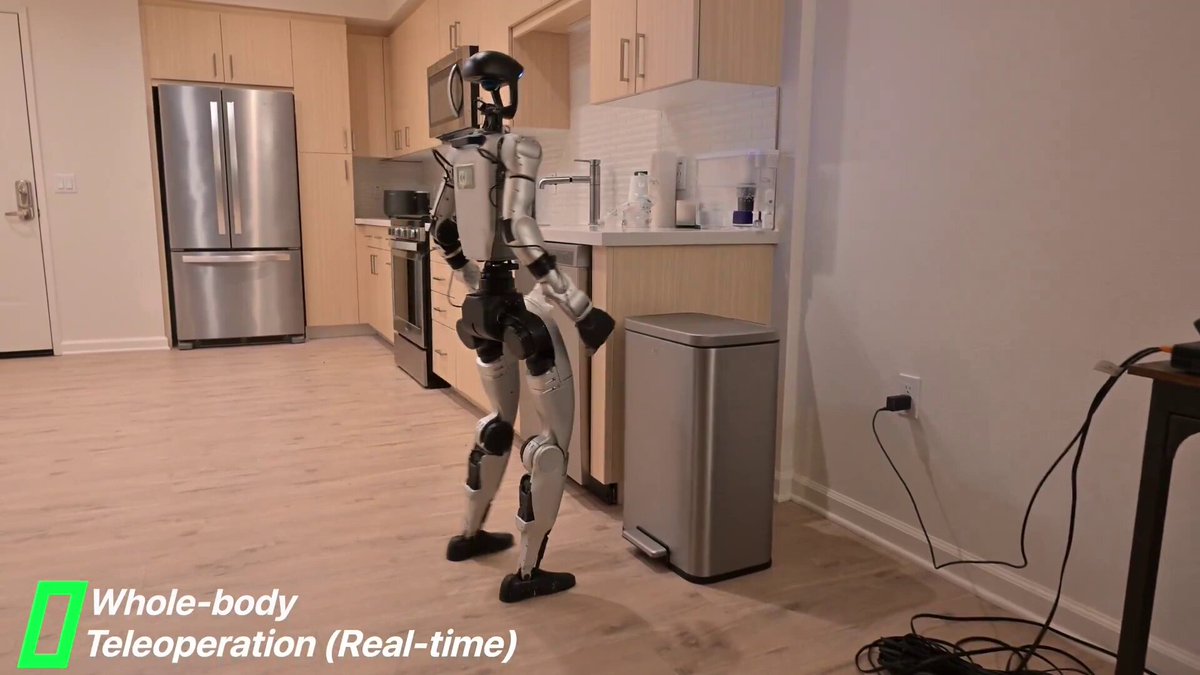
Can robots self-improve by collecting data autonomously🤖? Introducing SOAR: a system for large-scale autonomous data collection 🚀 and autonomous improvement📈of a multi-task language-conditioned policy in diverse scenes without human interventions .
47,739 просмотров • 2 лет назад •via X (Twitter)
Комментарии: 9

I’m thrilled to present the first work of my PhD! We hope that SOAR (Scaled Collection for Autonomous Improvement) will pave way for large-scale collection of real-world robot data and self-improving robot policies. The autonomous dataset, SOAR-Data, is also available for use.
For more, see: - Paper: - Website: - And the excellent thread by @pranav_atreya detailing our approach! This work was co-led by me and @pranav_atreya, along with Abraham Lee, @HomerWalke, @Oier_Mees, @svlevine
@HomerWalke @oier_mees @svlevine

Cool work! Is there any implementation of this in simulation?
We mainly aimed to improve policies in the real world, so no simulation pipeline currently. However, it's very easy to modify the code for sim. We do plan to switch to a new API that enables the pipeline to work in both real and sim, stay tuned:
Thanks! Look forward to it

@berkeley_ai Is there any pre-trained model available for this? On which we can incrementally train?
@hemang_jos83913 Yea, we can release the models. Stay tuned!

#Caduceus is excited about #SOAR's potential! 🤖 Empowering robots to self-improve through autonomous data collection is a game-changer. This aligns with our vision of leveraging decentralized technology to foster innovation and adaptability in #AI.