正在加载视频...
视频加载失败
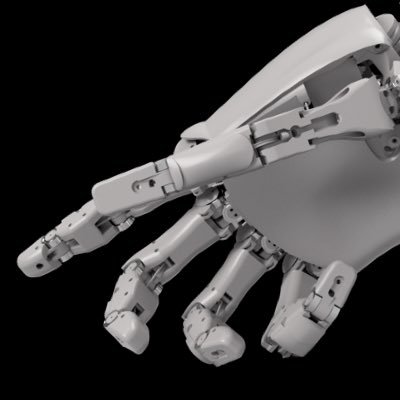
Morning testing. Range of motion test on all the joints. Moves a bit notchy because I’m stepping in degrees, but looks good overall!
10 条评论

coo chi coo chi coo

Cool..

Nice

Vibes.

Definitely hard to not draw that reference. I think of that scene frequently.

this reminds of the old article

Really nice work! The tendons look very well routed in this new design. How strong is the holding torque with the new servos?
Thanks Ian! To be honest, I’m not 100% sure on the torque yet. I have the limits on the servos set at 40% at the moment to avoid catastrophes during testing. That provides a very firm grip on stuff I’ve tried to grab with the hand. No idea what happens if I bump that higher yet.

Nice work. How much weight does it carry?
Not certain yet. It needs to get a little farther in terms of control to be able to grasp onto things well. Would estimate 1kg or so, but that’s a pure guess right now. May well be capable of more.
相关视频


Sensitive content
Morning !!!! It’s a new week so let’s all make the effort to make it a good one I’m off out in a bit for coffee etc so who’s stepping up Your sacrifice is my delight 😵💫 Get in my DMs for details #feetworshi̇p #footfetısh #soles #sexyface #sweatyfeet #alphadaddy #cashmaster #paypig
Alpha Godfather
46,158 次观看 • 2 个月前


