Загрузка видео...
Не удалось загрузить видео
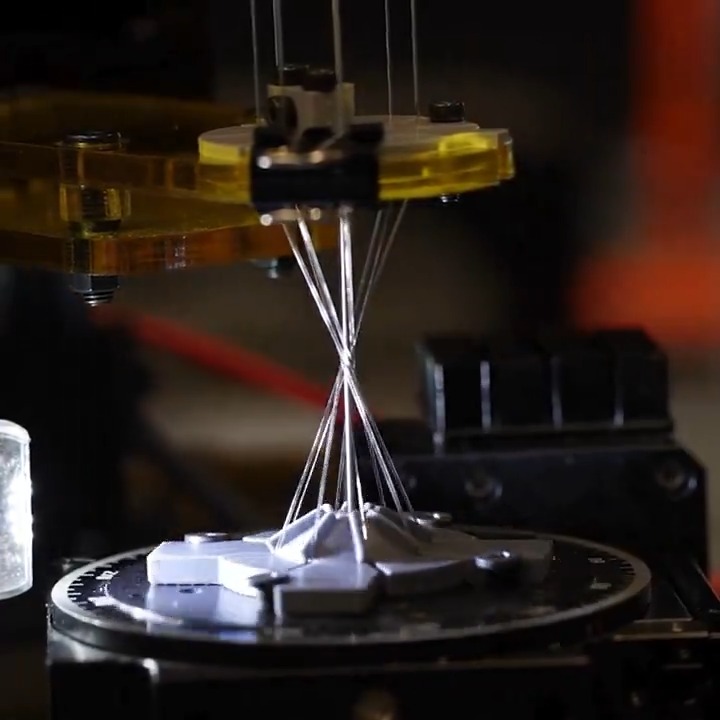
This is WILD! MIT just solved one of the hardest unsolved problems in robotics (Save this). For decades, the fundamental problem with soft robots and wearable exoskeletons has not been compute or AI, it has been actuation. The moment you try to give a soft robot meaningful strength, you... show more
1,208,301 просмотров • 4 месяцев назад •via X (Twitter)
Комментарии: 34

We spotted Nebius at +108%, AMD at +102%, CRDO at +70% before the runs. This MIT breakthrough points directly to the next set of winners. Come find them with us for a dollar.

We (1X) spent 10+ years building Tendon Drives (Custom Motors & Tendon Drives) to address this exact issue. Cool post-- but you deserve jail for associating us with this misinformation. "actuators that are too rigid, too loud, too heavy, or too dependent on infrastructure to operate naturally alongside humans." @CNviolations @CommunityNotes get his ass!

Anime Knights & Magic (2017)

The irony is every time they have a ‘breakthrough’ technology the replicates human perfection it ends up being just a replica of human technology Who created humans? @elonmusk Whoever did is obviously living 100,000 years in the future.

Cool. We are getting closer.
Yes! We are!

This is awesome! My lab at MIt did a bunch of work on exoskeleton

Starting to look like Westworld! Exciting… and i’m glad we already have a high-quality cautionary tale of what that can become.

@grok which companies are leading in the exploration of this technology

Whoa isn't that how Muscles work? You send electrical signals and they flex to the desired point, are we just super complicated biological robots?

actuation without heavy external pumps is the exact unlock humanoids need.

@grok Will this material be easy to scale and produce?

This feels like one of those enabling hardware breakthroughs — not an incremental improvement but a capability shift. If the community can solve integration, safety, and manufacturing challenges at scale, we could see a rapid wave of wearable robots, compliant humanoids, and soft prosthetics in the coming years. Would you like a brief summary suitable for a social post or a short thread that highlights the tech and its implications?

They must have got it from watching Westworld.

Applying MIT's electrofluidic fiber muscles (EFMs) to Tesla Optimus would be a transformative hardware upgrade, directly tackling the actuation bottlenecks that currently limit humanoid robots like Optimus (rigid, heavy, noisy geared motors concentrated at joints). Optimus Gen 2/3 currently weighs ~57 kg, uses custom electric linear/rotary actuators with planetary roller screws, and is optimized for factory tasks with ~28 body actuators plus advanced hands (22 DoF, 50 actuators total). It has solid payload (20 kg walking, higher for lifting) but remains somewhat stiff, audible, and power-hungry for broad consumer/home deployment. EFMs are thin (<2 mm), weavable textile fibers that act as self-contained artificial muscles: electrohydrodynamic (EHD) pumps drive fluid in a closed-loop antagonistic pair (one contracts while the other extends, exactly like biceps/triceps), delivering 50 W/kg power density (matches human skeletal muscle), 20% strain, and ~0.3-second response time. They’re silent (no moving parts), lightweight, fully untethered (no external pumps/reservoirs), and scalable by simply bundling or weaving fibers. Demos include a bundled muscle lifting 4 kg (200× its weight), a woven arm bending 40° for a compliant human handshake, and fast object launches.

actuation is where the real magic happens. can’t wait to see what this unlocks.

Piezoelectric actuators are solid-state and don’t require fluid at all, matching this technology’s parameters.

Woah. 😎

Hardware has been the main block for years. This finally makes robots that can actually work in a home.

@exponentialluke long-term impact on REE demand from humanoid robots?

Westworld is real

the real breakthrough isn't even about actuation itself, but how they've applied advances in materials science to fundamentally change the design constraints around soft robots. that's what allows for actual progress on wearables and exoskeletons

How long until Myomer muscles so I can build a Shadow Hawk?

rather than put it in a robot. how about putting it into a wearable suit for a human? you now have strength assist charged with kinetic energy?

@grok is the source EHD or McKibben/Dielectric elastomer

This is the kind of hardware unlock that changes everything downstream. Silent, untethered, weavable muscle that matches human power density — the robotics bottleneck just moved. The IP race around this starts immediately.

That’s a pretty intelligent design

Where have I seen this before???

The fundamental breakthrough here is moving from hand-crafted physics models to learned contact dynamics. Same paradigm shift happened in NLP — we stopped writing grammar rules and let transformers learn language structure. Robotics was the last holdout because physical interaction has zero tolerance for hallucination.

That's really cool if it can be scaled

@MilkRoad I look forward to a tuxedo in the style of Jackie Chan

Great, another step closer to the Terminator ☹️

Should have kept this quiet. Right now @elonmusk xAI is working on mimicking this solution. China, Korea, Meta, Google, Amazon as well. Microsoft. They will work on building their own and then monetizing their version of this, charging us all for it, replacing us with it and eventually Cyberdyne pushes that button. So, nice job.

Wil need to hit 30% contraction to match human movement but very promising. How efficient is it compared to hydraulic actuators?