正在加载视频...
视频加载失败
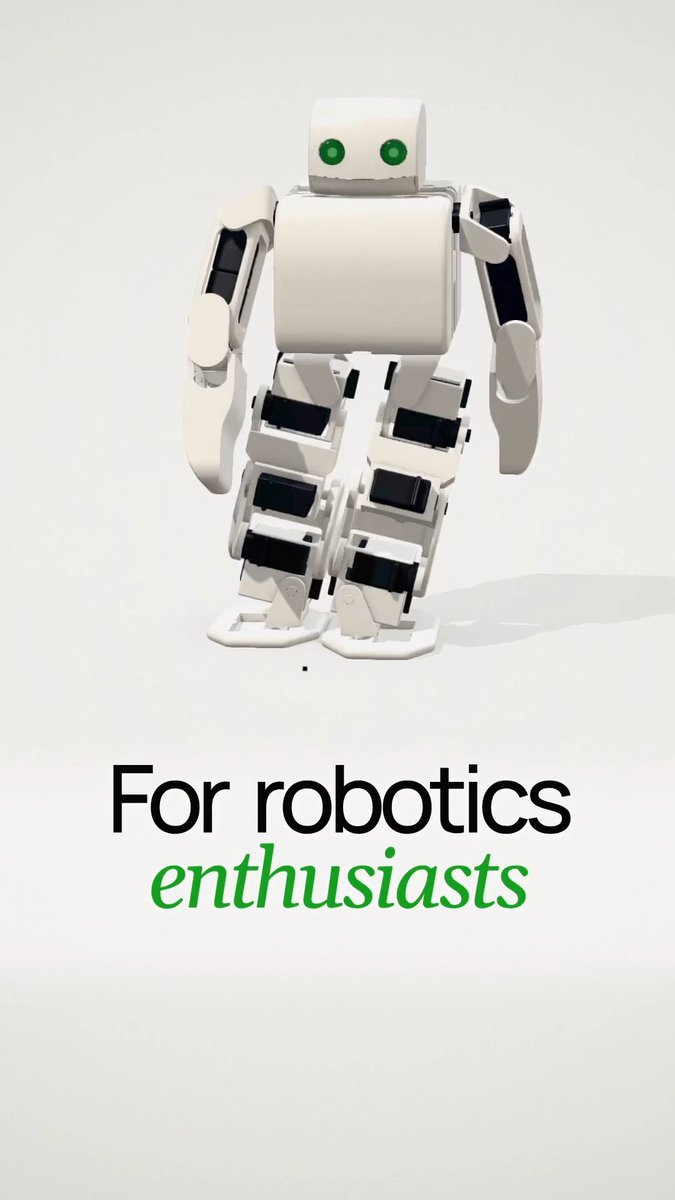
Your next robotics project could start with these steps. Today, we're open-sourcing Asimov 1's locomotion policy and the training code behind it, giving developers a foundation to build on. Alongside the trained policy checkpoint, we're sharing our Isaac Lab-based training code, including reward definitions, hardware-tuned actuator configurations, and domain... show more
5 条评论

Σ1 个月前
Love the project but the next step should definitely be to work on the legs so it doesn't walk like Biden

Asimov1 个月前
It's now open-source. Your best walk is one pull request away 🧡

Roushan1 个月前
Awesome

satvik1 个月前
Wow finally!!!

Indem1 个月前
Shipping the actuator config alongside the checkpoint is the detail I like here. For a deployed fleet, I’d carry that pairing into each robot’s run history. “Latest version” gets vague fast when hardware starts diverging.