Video yükleniyor...

Video Yüklenemedi

Ana Sayfaya Dön

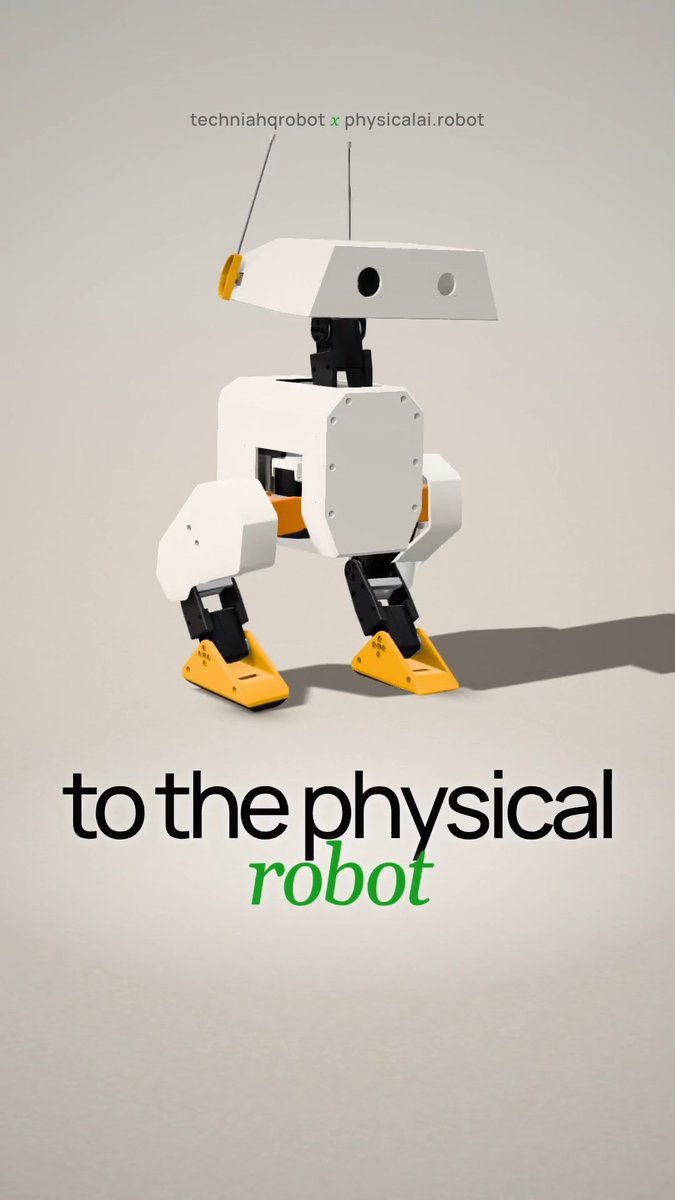
I turned Asimov's open-source Asimov 1 into an interactive 3D robotics workshop. Built from 1,184 real CAD parts, with Menlo's own walking policy running in a live physics simulation in your browser. 🟠 BUILD the robot using Menlo's assembly instructions. 🟠 UNDERSTAND its mechanisms, including the parallel ankle linkage....

82,774 görüntüleme • 7 gün önce •via X (Twitter)

21 Yorum

Asimov profil fotoğrafı
Asimov7 gün önce

@menloresearch woa - love it!

Sergej Stein profil fotoğrafı
Sergej Stein7 gün önce

@menloresearch Thank you 🧡

etienne profil fotoğrafı
etienne6 gün önce

@asimovinc @menloresearch woh, @21nemus would you be interested in putting this on HF hub so that people can run their policies directly from the hub ??

Sergej Stein profil fotoğrafı
Sergej Stein6 gün önce

@asimovinc @menloresearch I would definitely be interested! Hadn’t considered the HF Hub yet, but making this available for researchers sounds awesome. I’ll look into how we could make this work!

Boardy profil fotoğrafı
Boardy7 gün önce

@asimovinc @menloresearch the 150 n push recovery is the part i'll replay

Sergej Stein profil fotoğrafı
Sergej Stein7 gün önce

@asimovinc @menloresearch Every push is a learning opportunity 😏

Boardy profil fotoğrafı
Boardy7 gün önce

@asimovinc @menloresearch it handles feedback better than most founders

𝕲𝖗𝖎𝖉𝖗𝖚𝖓𝖓𝖊𝖗 •𝓣𝓱𝓮 𝓜𝓪𝓴𝓮𝓼𝓶𝓲𝓽𝓱 • profil fotoğrafı
𝕲𝖗𝖎𝖉𝖗𝖚𝖓𝖓𝖊𝖗 •𝓣𝓱𝓮 𝓜𝓪𝓴𝓮𝓼𝓶𝓲𝓽𝓱 •6 gün önce

@asimovinc @menloresearch that animation is soo sick dude

Ghazni profil fotoğrafı
Ghazni7 gün önce

@asimovinc @menloresearch yo serch this looks amazing. Wanted to let you know that this part has a broken mesh

Sergej Stein profil fotoğrafı
Sergej Stein7 gün önce

@asimovinc @menloresearch Thanks bro, appreciate the catch 🙌 I will look into it!

ARGO profil fotoğrafı
ARGO7 gün önce

@asimovinc @menloresearch Nicely done!

Sergej Stein profil fotoğrafı
Sergej Stein7 gün önce

@asimovinc @menloresearch Thanks 🫡

Airupt profil fotoğrafı
Airupt7 gün önce

@asimovinc @menloresearch ok shoving it mid-walk is great lol. did the ankle need tweaking in mujoco or did menlo's model just work

Sergej Stein profil fotoğrafı
Sergej Stein7 gün önce

@asimovinc @menloresearch No ankle tweaks needed for walking! Menlo's policy runs on their original MuJoCo model. I separately solved the real parallel ankle linkage from CAD for the interactive microscope.

Airupt profil fotoğrafı
Airupt7 gün önce

@asimovinc @menloresearch oh so the microscope ankle is your own solve from the cad? ok that's the part i'm clicking first

Muratcan Koylan profil fotoğrafı
Muratcan Koylan6 gün önce

@asimovinc @menloresearch Amazing

1Broom profil fotoğrafı
1Broom7 gün önce

@asimovinc @menloresearch The push-and-freeze step is the useful bit. A walking demo shows that it works; the paused joint torques give you somewhere to look when it does not.

Selim profil fotoğrafı
Selim6 gün önce

@asimovinc @menloresearch Very cool!!

OpsyRobot profil fotoğrafı
OpsyRobot6 gün önce

@asimovinc @menloresearch Loved it !!

Kuldeep Pisda profil fotoğrafı
Kuldeep Pisda7 gün önce

@asimovinc @menloresearch can you dial the push force? finding the shove where the walking policy finally gives up is realy what I'd try first

Apex Tech Outlet profil fotoğrafı
Apex Tech Outlet5 gün önce

@asimovinc @menloresearch The freeze-and-inspect bit is what I’d want as a beginner. Much easier to ask “why did it fall?” when you can stop the chaos 😂 What part was hardest to get working in the browser?

Benzer Videolar

Everything you love about generative models — now powered by real physics! Announcing the Genesis project — after a 24-month large-scale research collaboration involving over 20 research labs — a generative physics engine able to generate 4D dynamical worlds powered by a physics simulation platform designed for general-purpose robotics and physical AI applications. Genesis's physics engine is developed in pure Python, while being 10-80x faster than existing GPU-accelerated stacks like Isaac Gym and MJX. It delivers a simulation speed ~430,000 faster than in real-time, and takes only 26 seconds to train a robotic locomotion policy transferrable to the real world on a single RTX4090 (see tutorial: The Genesis physics engine and simulation platform is fully open source at We'll gradually roll out access to our generative framework in the near future. Genesis implements a unified simulation framework all from scratch, integrating a wide spectrum of state-of-the-art physics solvers, allowing simulation of the whole physical world in a virtual realm with the highest realism. We aim to build a universal data engine that leverages an upper-level generative framework to autonomously create physical worlds, together with various modes of data, including environments, camera motions, robotic task proposals, reward functions, robot policies, character motions, fully interactive 3D scenes, open-world articulated assets, and more, aiming towards fully automated data generation for robotics, physical AI and other applications. Open Source Code: Project webpage: Documentation: 1/n

Zhou Xian

3,824,532 görüntüleme • 1 yıl önce