Video wird geladen...
Video konnte nicht geladen werden
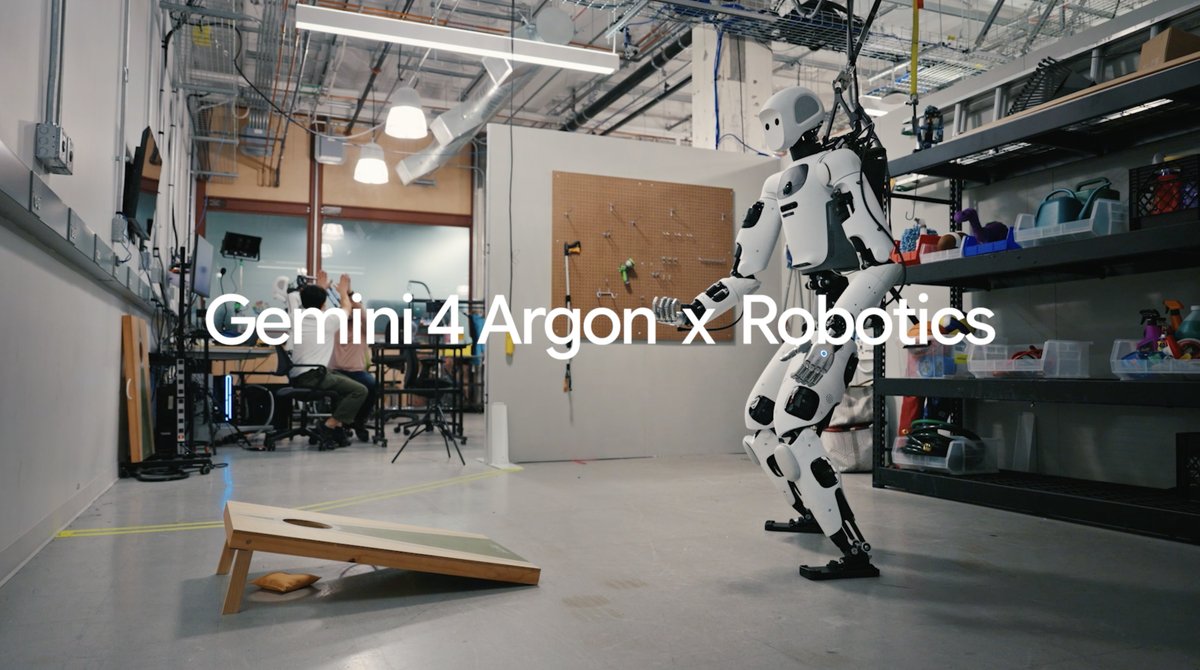
A generalist model, not a dedicated robot policy, pulled off physical control by reasoning and using tools. Here's the four-step approach Gemini 4 figured out, given high-level instructions and the overall task: 1. Watched a human throw, and mapped the motion to its own joints. 2. Used its cameras... show more
10,160 Aufrufe • vor 21 Tagen •via X (Twitter)
4 Kommentare

Watching a person move and mapping that onto its own joints without a dedicated robot policy is quietly enormous

One thing Apptronik have definitely got right with their humanoid, in my opinion, is the head, which I believe is very important. I love the two camera eyes and the soft flashing LED mouth when it speaks. 👍👍👍

A general model doing physical control via tool use is a big shift from bespoke policies. If that holds, the value moves to hardware makers like Apptronik and component suppliers. Curious how latency looks in real time.

Generalist models are at least the glue that will make humanoids coherent in all situations. They need a relatable and flexible default behavior in-between learned skills.