正在加载视频...
视频加载失败
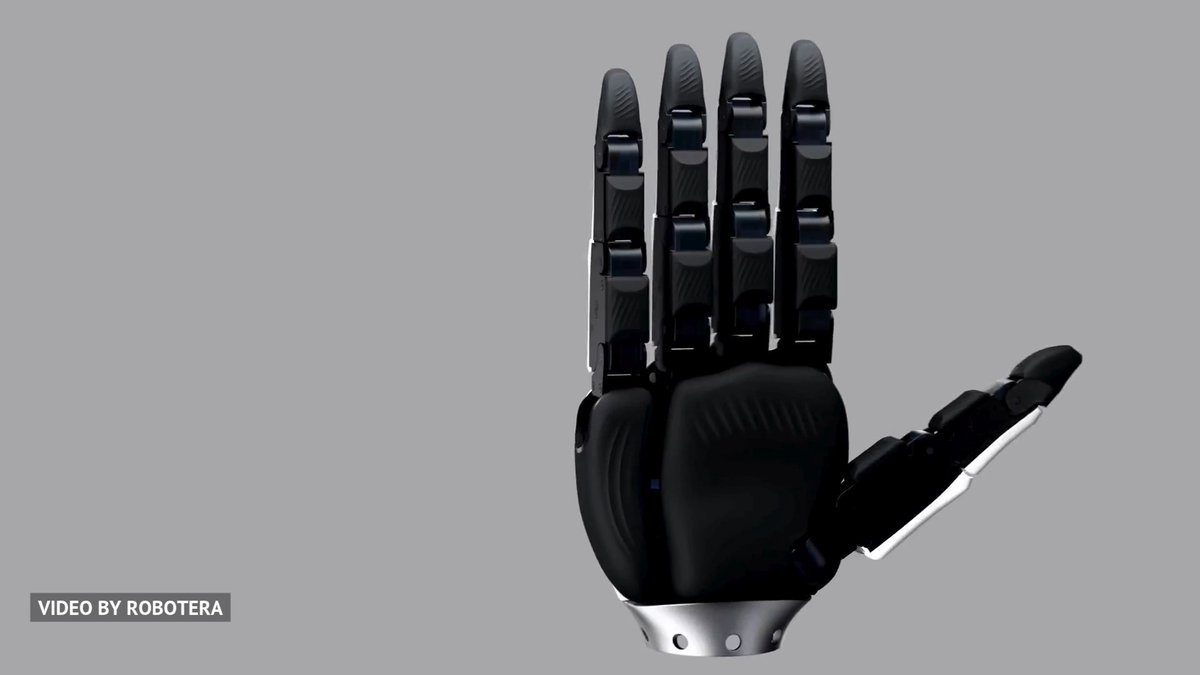
it's time to drop three new #opensource robotic hands! this time with tactile sensors! Tweak it, 3D print it, and use them in your robotics and physical AI research! Here are some wild examples ↓↓↓

369,780 次观看 • 7 个月前 •via X (Twitter)
46 条评论

we'll give access to every source and print file of the orcahand base version to give you full creative freedom for your use cases.
One of our variants is the orcahand touch. It comes with up to 83 taxels per fingertip, 1mm resolution, and 0.1N force detectability.
we'll soon publish a detailed assembly manual - LEGO style!
Another version that we've built is the orcahand lite. It is compliant, adaptive and has a lightweight human form factor.
We're excited to see what the community will build with them. From hardware to robotic learning.
If you want to get started as fast as possible, configure your hand on our website now:

is a direct drive hands in the works as well?
stay tuned ;)

can i buy it already made
you can right here
Let's say I build the arm I just need the hand, if I get the cheapest hand you have, how much weight can it pick up before it fails? So can it pick up a red brick or 3 lb or 5 lb Etc?

@orcahand orcahand lite is great at grasping so I‘d say it‘ll do the job but you‘ll definitely push it to the limits!
@orcahand Well can't I just send the cad files to CNC shop to make these parts in aluminum or something? Because I have to have at least one single strong arm with a hand that could grip something at least the weight of a red brick. It has to reach out two or three feet & down about 18 in

Shadow Hand's 2024 benchmarks show tactile sensors improving grasp success from 78% to 95% on irregular objects-integrate with ROS2 for real-time feedback, cutting training data needs by 40% in sim-to-real transfers.

Awesome! Software was just the warmup. Physical AI is the next frontier. The ability to just 'tweak' and 3D print your own hardware is exactly why open-source will win in robotics!

4 hands built this.
soon I will build myself

This is just incredible. Many companies are striving to get this level of dexterity and you share it with the world. Respect. Great value you are sharing to the world.

This is insane, time to ping @lachygroom
@lachygroom thanks vedant

assembling a dexterous robotic hand in 8 hours for $2,200 is kinda insane, open source hardware is moving faster than most people realize

Open-source hardware + tactile sensing is huge. The hands are getting better fast. Next bottleneck: training data diverse enough to teach them real tasks. Right now most dexterous manipulation datasets are lab-only. Getting this kind of data from actual production environments is the gap nobody's filling yet.

Awesome work @clemens_chr and team!🚀

The tactile sensor addition is a game changer -- how sensitive are they compared to commercial options and can they detect things like texture differences or just pressure 🤔

What printer(s) do you recommend?

Fitting name for such a dexterous hand. Well done team!

@arnie_hacker Amazing work team!

Love this and thanks for making it open source

Really cool work! Suggestion: Publish a combination with an arm like the ones by @RobotLearningCo or so, I think this might hold a lot of people back from using hands (same for the Amazing hand by HF!)

Cool. Where are the STL files and BoM, so that we can get started.

you doing a great job! thanks
Hi! I’d love to translate and repost this video on the Chinese social media platform RedNote. I would of course credit your company name and X account. Would that be okay with you?

Can't wait for this to land; this is the largest remaining obstacle before fine manipulation. I have so many questions though; especially around latency and heat dissipation. Excited to play with it!

So good 🤯

Nice! •Hammer only down, can fingers be hammered up? Uses return springs? •Off the shelf Paxini tactile sensors, ya? •±5° per joint before sensors is quite high, does that include the coupled dofs too? Or are those not measured? •Joint torque sensors? •Any tendon wear data?

Cooked big time

we r truely cooked, this is insane

awesome job!

@yoheinakajima

Insane work, congrats guys !

The unthreading nut demo is one of the more impressive-yet-understated kinematics demos I’ve seen.

😮

wow

Amazing work, we’re definitely making few of these for us at REVEL

Open-source tactile hands are a massive unlock. The missing piece is still training data — 83 taxels per fingertip is useless without diverse demonstrations of what to do with them. Hardware democratization has raced ahead of the data pipeline.

9wSZbC64PfKhsE7dW5GAeEBeQGitPBMV3hLUuLB9pump It’s yours?