正在加载视频...
视频加载失败
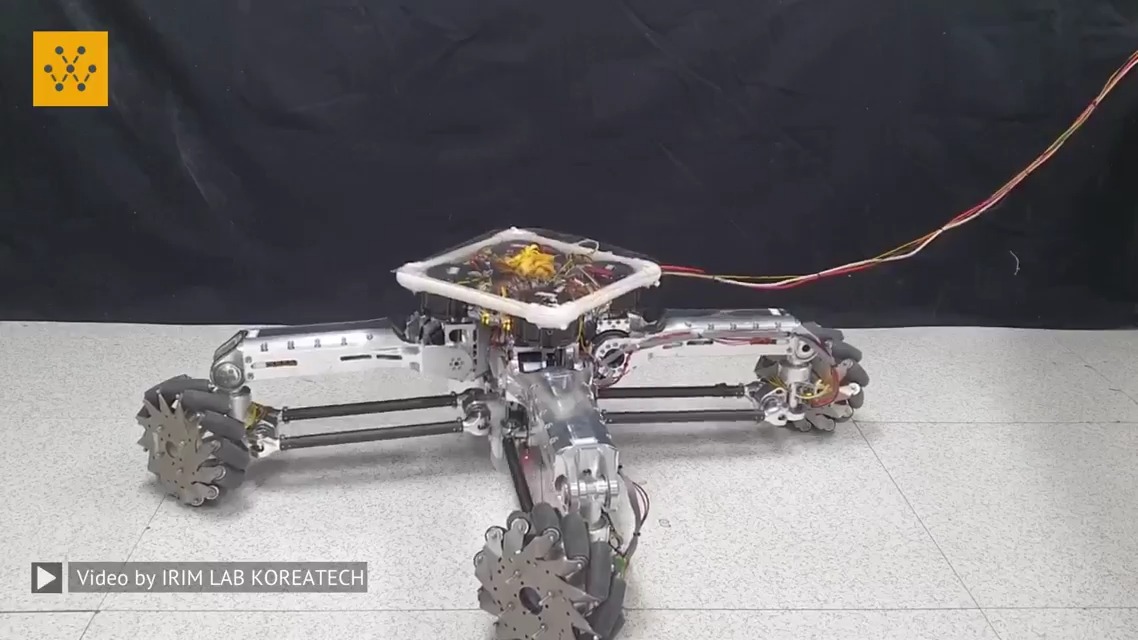
Last year, I designed a cute omnidirectional robot with a LIDAR, IMU, thermal camera and hotswappable battery. It uses QDD actuators for the 3 wheels Hardest part was integrating everything into a very small form factor walkthrough build
21,114 次观看 • 5 天前 •via X (Twitter)
8 条评论

Sadok5 天前
the packaging constraint on this must have been a nightmare

Vincent Nguyen4 天前
Yes, it was very hard, especially since I didn't design any custom PCB for this so had to fit off the shelf parts

Mathilde Anita5 天前
Trop cool

Kunal Mehta4 天前
@grok which are the components are used in this project
Mathilde Anita5 天前
Il est super mignon

Nathan Handyman5 天前
Did you model this in Fusion? The omni wheels look like a nightmare to print.
Vincent Nguyen4 天前
The robot was made in fusion, and the wheels were modified from an open source project
Nathan Handyman4 天前
This happens when you model cool omni wheels before checking the print bed. Did they print in one piece?