Video wird geladen...

Video konnte nicht geladen werden

Zur Startseite

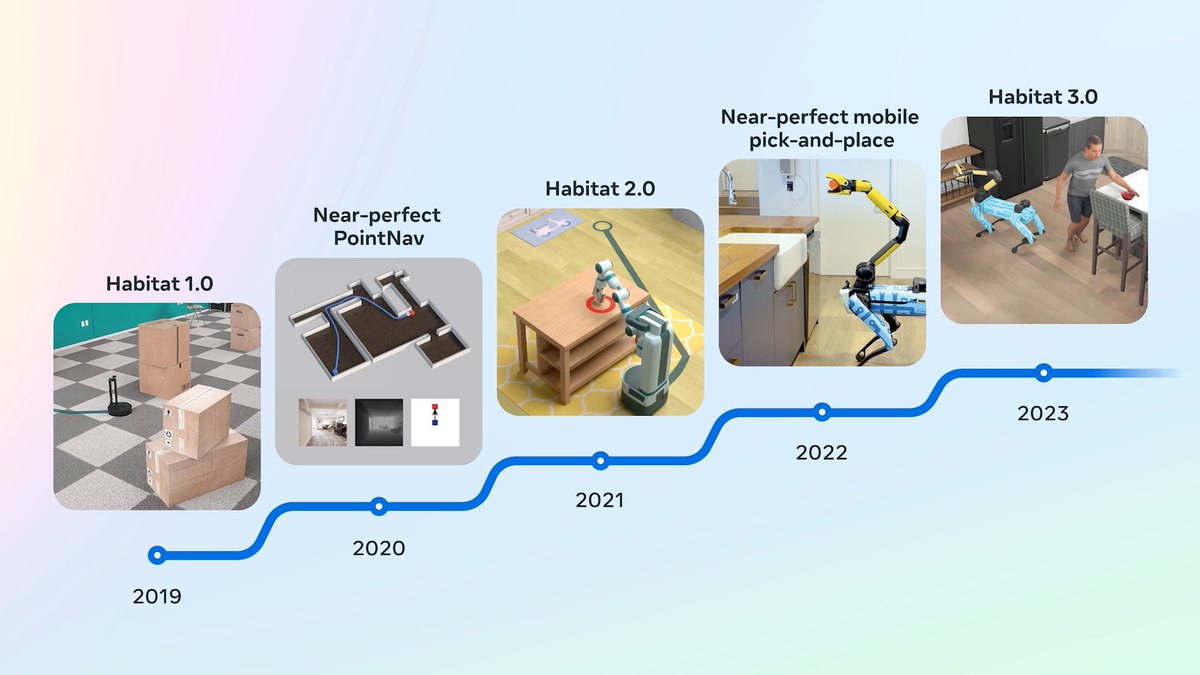
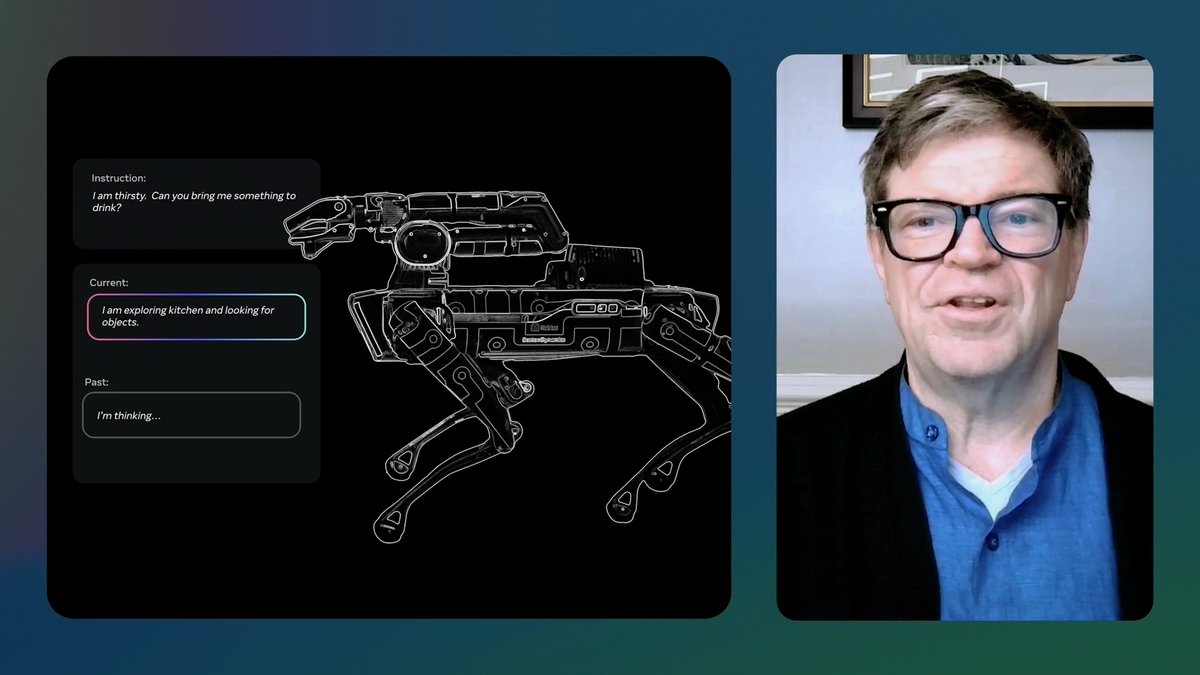
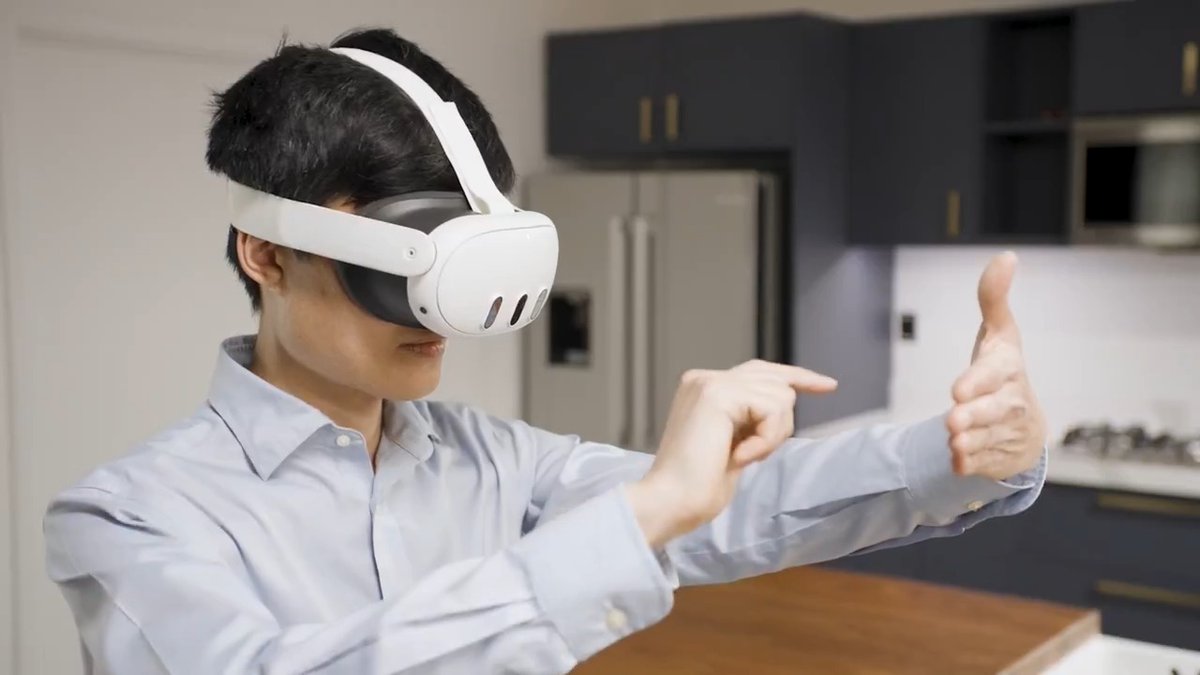
Meta PARTNR is a research framework supporting seamless human-robot collaboration. Building on our research with Habitat, we’re open sourcing a large-scale benchmark, dataset and large planning model that we hope will enable the community to effectively train social robots.
107,091 Aufrufe • vor 1 Jahr •via X (Twitter)

11 Kommentare

Profilbild von AI at Meta
AI at Metavor 1 Jahr

More on our newest releases and impact of the open source work developed by Meta FAIR ➡️

Profilbild von Togoda Search Engine
Togoda Search Enginevor 1 Jahr

Togoda is Google on Steroids with AI summaries . 🚀 The only thematic AI search engine.👀 It's 100% private with third party proxy. 🧨 Try it today & experience the difference! 👉Follow us @togoda_com 👈 🚀Help us grow & share this post!🚀

Profilbild von Tinna
Tinnavor 1 Jahr

Training social robots? We've got the humans for that! 😉 500,000+ contributors ready to teach bots manners (and maybe some dance moves). Check out our premium training data. #PublicAI

Profilbild von Abdellah Ht
Abdellah Htvor 1 Jahr

Truly Open AI 🔥

Profilbild von Dan Advantage
Dan Advantagevor 1 Jahr

yeah, this is really cool actually. but i won't recant metaai is still trash

Profilbild von Tenkaizen
Tenkaizenvor 1 Jahr

That's quite the development for human-robot collaboration

Profilbild von Electe
Electevor 1 Jahr

@AIatMeta, open source creates immense opportunities for innovation. 🌟

Profilbild von Data & Analytics
Data & Analyticsvor 1 Jahr

@AIatMeta, exciting developments ahead! The blend of open source with Meta FAIR’s innovations could reshape our tech landscape in meaningful ways. How do you see this influencing future projects? 🌟 #Innovation

Profilbild von Soham Ratnaparkhi
Soham Ratnaparkhivor 1 Jahr

This is super intriguing! Agents are cool, but when that AI goes into a robot, that is what will make AI very powerful.

Profilbild von Dan Costello #JobSearch #HireMe #Asia #Arabia
Dan Costello #JobSearch #HireMe #Asia #Arabiavor 1 Jahr

Are these robos self-cleaning?

Profilbild von Aleksei Dolgikh 2025 | CVO, Scout VC, Collaborator
Aleksei Dolgikh 2025 | CVO, Scout VC, Collaboratorvor 1 Jahr

Research 🔬

Ähnliche Videos

Open science is how we continue to push technology forward and today at Meta FAIR we’re sharing eight new AI research artifacts including new models, datasets and code to inspire innovation in the community. More in the video from @jpineau1. This work is another important step towards our goal of achieving Advanced Machine Intelligence (AMI). What we’re releasing: • Meta Spirit LM: An open source language model for seamless speech and text integration. • Meta Segment Anything Model 2.1: An updated checkpoint with improved results on visually similar objects, small objects and occlusion handling. Plus a new developer suite to make it easier for developers to build with SAM 2. • Layer Skip: Inference code and fine-tuned checkpoints demonstrating a new method for enhancing LLM performance. • SALSA: New code to enable researchers to benchmark AI-based attacks in support of validating security for post-quantum cryptography. • Meta Lingua: A lightweight and self-contained codebase designed to train language models at scale. • Meta Open Materials: New open source models and the largest dataset of its kind to accelerate AI-driven discovery of new inorganic materials. • MEXMA: A new research paper and code for our novel pre-trained cross-lingual sentence encoder with coverage across 80 languages. • Self-Taught Evaluator: a new method for generating synthetic preference data to train reward models without relying on human annotations. Access to state-of-the-art AI creates opportunities for everyone. We’re excited to share this work and look forward to seeing the community innovation that results from it. Details and access to everything released by FAIR today ➡️

AI at Meta

150,647 Aufrufe • vor 2 Jahren

In my past research experience, finding or developing an appropriate simulation environment, dataset, and benchmark has always been a challenge. Missing features, limited support, or unexpected bugs often occupied my days and nights. Moreover, current simulation platforms are relatively fragmented—making it challenging to replicate the success of the RT-X dataset in unifying community efforts. Introducing RoboVerse, we provide a unified platform, dataset, and benchmark for scalable and generalizable robot learning. We hope to build a shared foundation to combine the community efforts. RoboVerse includes: MetaSim: We carefully designed a configuration system and a universal interface to align current robotic simulators. With MetaSim, you can use any simulator with the same code—bringing together the community’s diverse efforts under one framework! RoboVerse Dataset and Benchmark: We unify popular simulation environments and benchmarks into a single cohesive system and introduce the RoboVerse dataset—a large-scale, high-quality synthetic dataset. Additionally, we propose a standardized benchmark across both imitation learning and reinforcement learning. A cool feature enabled by our unified framework: Hybrid Simulation! You can now integrate physics engines and renderers from different simulators—e.g., using MuJoCo precise physics with Isaac photorealistic rendering. This not only elevates simulation fidelity but also significantly enhances real-world transfer performance across complex robotic applications. Hopefully, our team’s efforts could serve the robotic community to thrive vibrantly in the years to come. RoboVerse is open-sourced🥳!!! Project Page: Documentation: Github Repo: Paper:

Haoran Geng

84,425 Aufrufe • vor 1 Jahr