Loading video...
Video Failed to Load
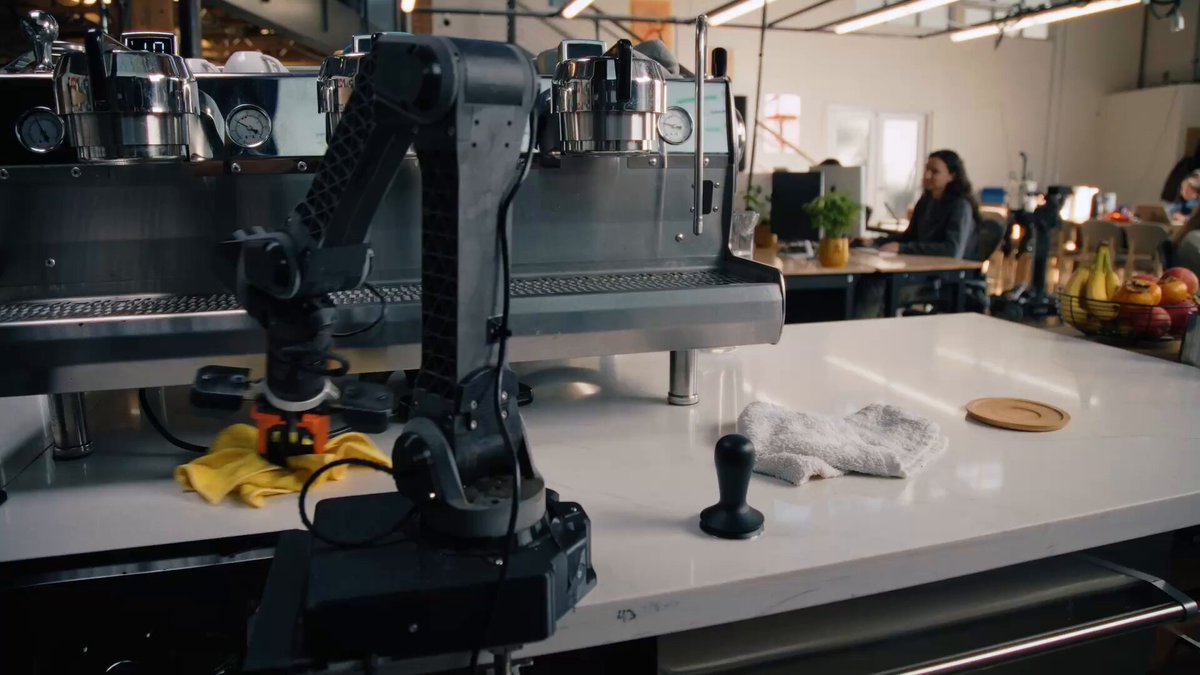
PokeBot has launched RoboAPI, a public API that lets robot arms perform new tasks without collecting data or training a dedicated model. Users can connect a supported arm with a wrist-mounted camera, give it a task such as "clean the table", and have RoboAPI send back its next moves... show more
10,415 views • 6 days ago •via X (Twitter)
23 Comments

RoboAPI runs on Poke-Aurora, PokeBot's first world-action model, which predicts what the camera will see next along with the arm's next moves. The technical preview is free and non-commercial. Supported arms include the UR5e, Franka, and YAM, fitted with a wrist-mounted action camera. Test it out 👀

a robot arm that picks up new chores without retraining is already more teachable than most roommates i've had

Does "clean the table" work on a properly messy table, or just a tidy demo one?

does it work on an so-101 or only certain arms

No task-specific training is the bold claim, but a wrist-mounted camera only sees what's right in front of the gripper. I'd want to see it clean a table where half the mess is out of frame before calling it zero-shot.

No training data per task. That changes robot economics.

Wrist camera only is the interesting constraint here. If the next moves come back over the network in near real time, latency is part of the control loop now. Curious how it behaves on a slow connection.

Per PokeBot's page it runs on their Poke-Aurora world-action model, turning camera observations plus your instruction into actions zero-shot. Real test is recovery: what does it send back when the arm drops the object halfway?

不训练就能教机械臂干活?

No data, no training, just "clean the table"… robot arms are starting to feel like an API call, not a research project.

skipping data collection is the big deal here. most robot projects die at "now record 500 demos." curious how it does on a messier table than the demo one

"no task-specific training" is the claim to test. the honest benchmark: one arm, a messy table it's never seen, 20 runs, count completions. and since the api sends back the next moves, latency is the safety story. i'd want a hard stop on the robot side if a reply comes late

RoboAPI letting robot arms take on new tasks without collecting data or training a dedicated model could help small robotics teams a lot

Curious about the control loop here. If the policy runs behind a cloud API, a latency spike mid-grasp becomes a real problem. A local safety layer that can stop the arm when the API gets the task wrong would matter more to me than the model itself.

this is amazing! Is it the first such API?

what happens when "clean the table" includes my laptop?

no task specific training would be huge if it holds up outside the demo. clean the table is the easy one tho, lets see it fold laundry

rosie the robot needed zero training data too. only took us 64 years

PokeBot launched RoboAPI: connect a supported arm with a wrist camera, give it a task like "clean the table," and get its next moves back in near real time. No data collection or task-specific training.

How many people actually have a supported arm with a wrist camera at home? Curious what the first tasks are that people teach it.

the part i'd test first is the network. if the next moves come back over an API, the control loop now crosses the internet. what does the arm do when a response is late or drops mid-grasp?

no data collection or training per task is the part that matters here

no training data is a big claim. show me it folding laundry first