Video wird geladen...

Video konnte nicht geladen werden

Zur Startseite

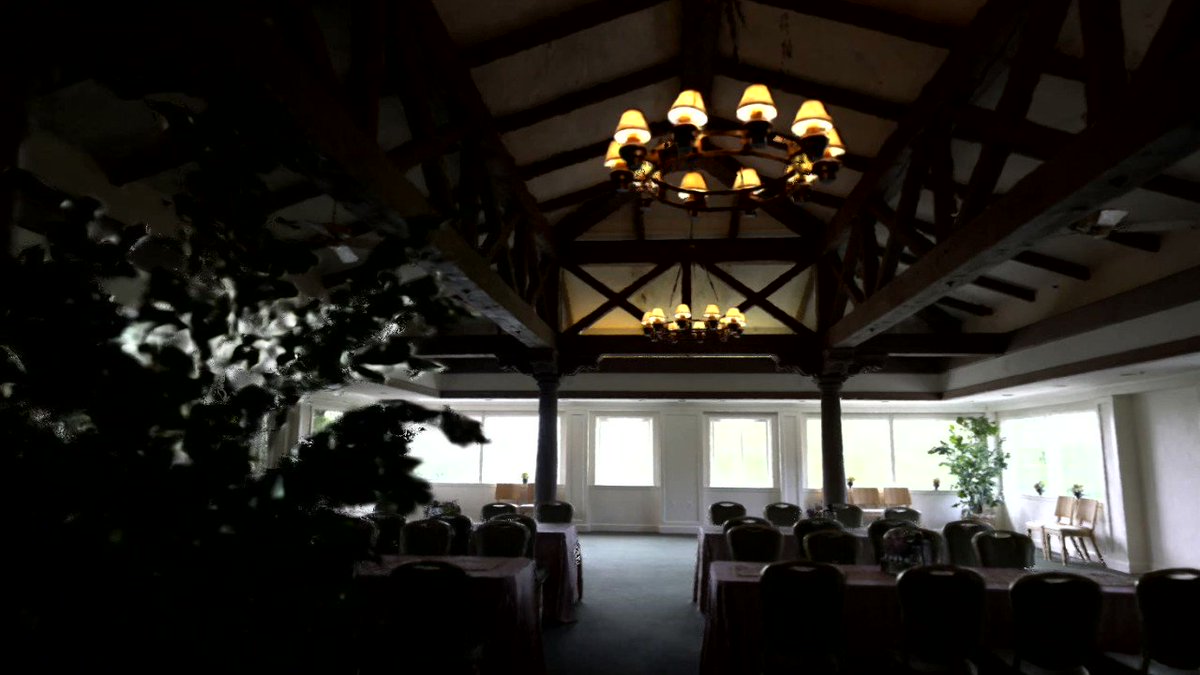
[SIGGRAPH '24] RTG-SLAM: Real-time 3D Reconstruction at Scale Using Gaussian Splatting Paper (pdf link): Project: Code: Method ⬇️ 1 I 2
35,675 Aufrufe • vor 2 Jahren •via X (Twitter)

7 Kommentare

Profilbild von MrNeRF
MrNeRFvor 2 Jahren

2 l 2

Profilbild von Surgeflow
Surgeflowvor 2 Jahren

There is something new and impressive coming out every day.

Profilbild von MrNeRF
MrNeRFvor 2 Jahren

It's crazy!

Profilbild von Nils Pihl (broodsugar.eth)
Nils Pihl (broodsugar.eth)vor 2 Jahren

That’s so hot.

Profilbild von Tim Reha
Tim Rehavor 2 Jahren

Super cool sweet!!

Profilbild von MrNeRF
MrNeRFvor 2 Jahren

Exactly!

Profilbild von Antoan Bekele
Antoan Bekelevor 2 Jahren

Is this actual SLAM or just reconstruction? I don't see poses or trajectory estimation.

Ähnliche Videos

MAGS-SLAM: Monocular Multi-Agent Gaussian Splatting SLAM for Geometrically and Photometrically Consistent Reconstruction TL;DR: The first RGB-only multi-agent 3D Gaussian Splatting SLAM for collaborative photorealistic scene reconstruction. Contributions: (1) We propose the first monocular RGB-only multi-agent 3D Gaussian Splatting SLAM system. It integrates Gaussian front-ends, compact submap summaries, inter-agent verification, Sim(3) submap pose graph, and occupancy-aware fusion into a unified framework, achieving accurate tracking and photorealistic reconstruction without depth sensors. (2) We propose a Pose-Graph Bundle Adjustment (PGBA)-consistent Sim(3) loop closure mechanism for multi-agent systems, which jointly resolves intra- and inter-agent scale drift through a submap-level Sim(3) pose graph coupling geometric and photometric residuals. Robustness is ensured by a spatial-extent gate that rejects degenerate loops and an adaptive edge invalidation scheme consistent with evolving PGBA corrections. (3) We propose an occupancy-aware fusion framework for coherent multi-agent Gaussian maps. It combines occupancy-grid deduplication, decoupled coordinator, and joint pose-Gaussian photometric refinement to eliminate duplicated Gaussians, residual misalignment, and photometric seams across agents. (4) We introduce ReplicaMultiagent Plus dataset. While existing multi-agent datasets are typically limited to 2-3 agents with short trajectories, our dataset scales to 4 agents with long-horizon trajectories. In addition, we provide ground-truth geometry and semantic annotations, supporting the evaluation of monocular, RGB-D, and semantic multi-agent SLAM for collaborative dense reconstruction.

MrNeRF

19,518 Aufrufe • vor 4 Monaten