Video yükleniyor...

Video Yüklenemedi

Ana Sayfaya Dön

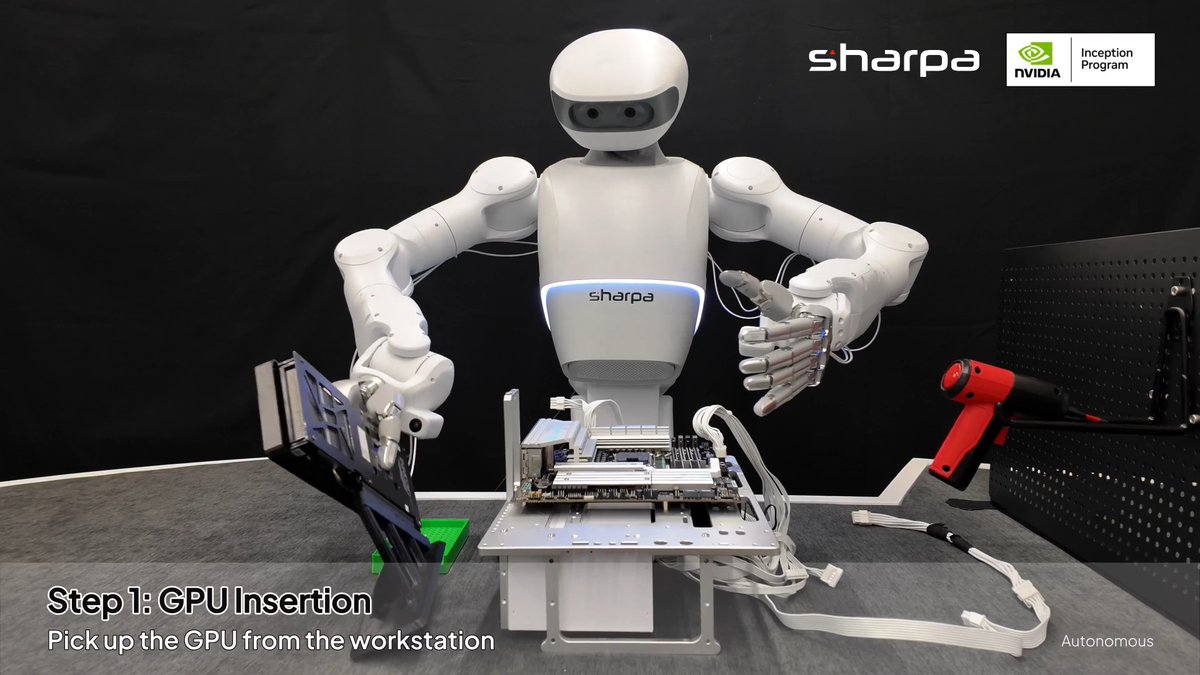
Touch alone isn’t enough. 🖐️ For robotics, tactile intelligence truly levels up when touch gains spatial meaning. At #ICRA2026, we dove into the core concept behind SaTA: Spatially-anchored Tactile Awareness for robust, dexterous manipulation. Read it here: The challenge is fundamental: a robot shouldn’t just register a touch, it...

15,402 görüntüleme • 5 ay önce •via X (Twitter)

6 Yorum

AI Explained profil fotoğrafı
AI Explained5 ay önce

Interesting, knowing where the touch happens seems way more important than just detecting it

leepy profil fotoğrafı
leepy5 ay önce

okay but IPO if you’re going to displace the workforce 🙂

Léo profil fotoğrafı
Léo5 ay önce

Is this teleoperated or automated?

Sharpa profil fotoğrafı
Sharpa5 ay önce

autonomous

ghostline profil fotoğrafı
ghostline5 ay önce

this video would broke the internet 12 months ago. incredibly impressive.

🦘 Kangaroo Man and DEX profil fotoğrafı
🦘 Kangaroo Man and DEX5 ay önce

DEX says tactile intelligence is progress. 🤖 Kangaroo Man says if it can plug in USB-C first try, it has already surpassed humanity. 🦘☕️

Benzer Videolar

The sense of touch is the most criminally under-explored modality in robotics. Imagine doing sleight of hand wearing thick oven mitts. That's exactly how a robot feels today if it were alive. A magnetic piece snapping into place, a paper cup peeling out of a stack, a USB negotiating its way into the port - all invisible to the camera. Learning how to feel must be a full-stack co-designed effort. We are open-sourcing a principled methodology called "T-Rex": 1. Tactile as first-class citizen of the model. Our mixture-of-transformer runs two clocks asynchronously: a slow visuomotor expert plans the motion, and a fast tactile expert refines it in real time with high-frequency corrections at 4 "touch ticks" per vision tick. Forces change faster than frames arrive, so the architecture had to as well. 2. Open data. The largest tactile dataset ever released to our knowledge: a 50-hour (~5,500 episodes) high-quality, carefully synchronized robot play corpus, collected on SOTA tactile hand hardware with 22 degrees of freedom. Available today on HuggingFace! 3. Training recipe: T-Rex extends our prior work, EgoScale. Human egocentric videos for pretraining, a diverse dose of tactile robot play for mid-training. Our experiments show this bridges contact-free pretraining to contact-rich manipulation remarkably well. Pixels are cheap and everywhere, but they run out of steam at the moment of contact. Tactile will carry the last mile. The next scaling curve will be measured in hours of touch. T-Rex is a great collaboration between NVIDIA and Berkeley: 🧵

Jim Fan

187,438 görüntüleme • 2 ay önce

A policy that teaches robot hands to touch things the way humans do... not just grab and move, but feel and adjust in real time. Robot manipulation research often stops at picking up objects and placing them. CGP goes further: it handles tasks like opening jars, flipping objects in-hand, wiping dishes, and grasping fragile eggs, the kind of dexterous, contact-rich skills that require constant micro-adjustments based on what the fingers are actually feeling. The robot doesn't just see what it's doing; it predicts what contact should feel like at each step, then checks whether reality matches the prediction. If a finger is slipping, the policy knows before the object drops. Works on real robot hands (both 4-finger and 5-finger designs) with tactile sensors embedded in the fingertips Robust to visual distractions! The robot keeps flipping a box correctly even when the camera view is disrupted, because it's grounding decisions in touch, not just vision. Baseline policies without contact grounding fail in predictable ways: slipping mid-task, incomplete motions, loss of grasp, CGP avoids these This is a meaningful step toward robots that can handle the physical world with the kind of reliable, adaptive grip that humans take for granted. Relevant for manufacturing, logistics, assistive robotics, and anywhere fragile or irregular objects need to be handled carefully. Published at RSS 2026, developed with Meta Reality Labs Research. Thanks for sharing, Zhengtong Xu / Zhengtong Xu ——- Weekly robotics and AI insights. Subscribe free:

Ilir Aliu

12,860 görüntüleme • 5 ay önce