RAI Institute
@rai_inst • 8,432 subscribers
We aim to solve the most important and fundamental problems in robotics and AI. (Formerly The AI Institute)
Shorts

Videos
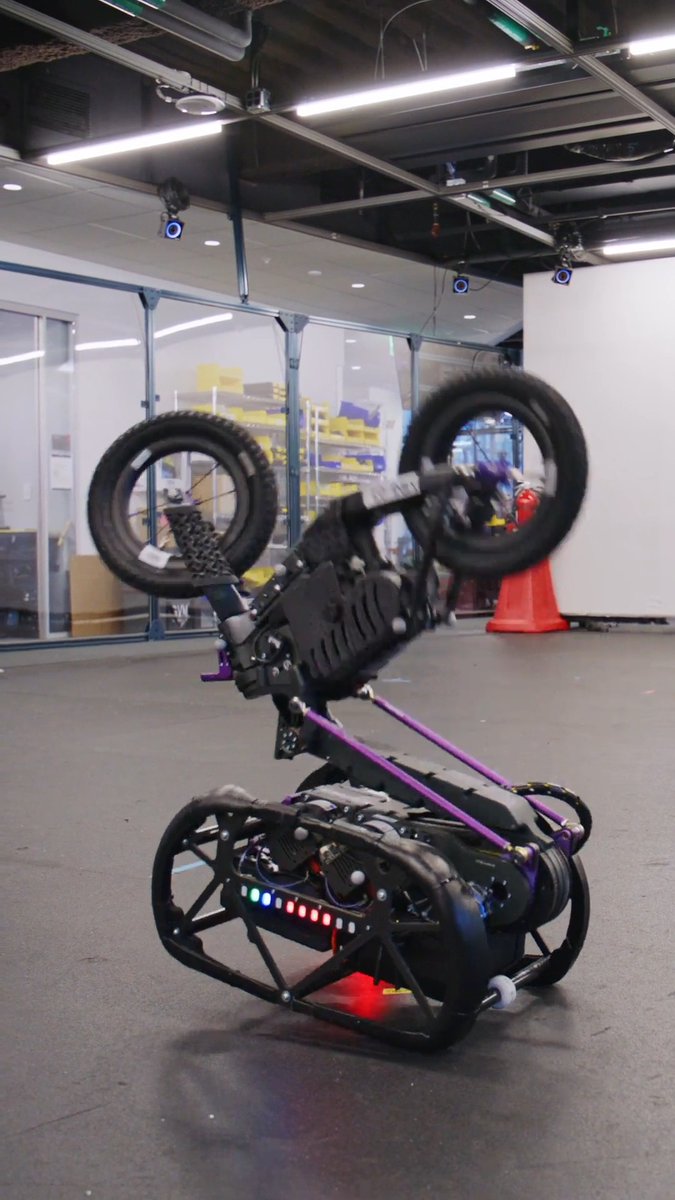
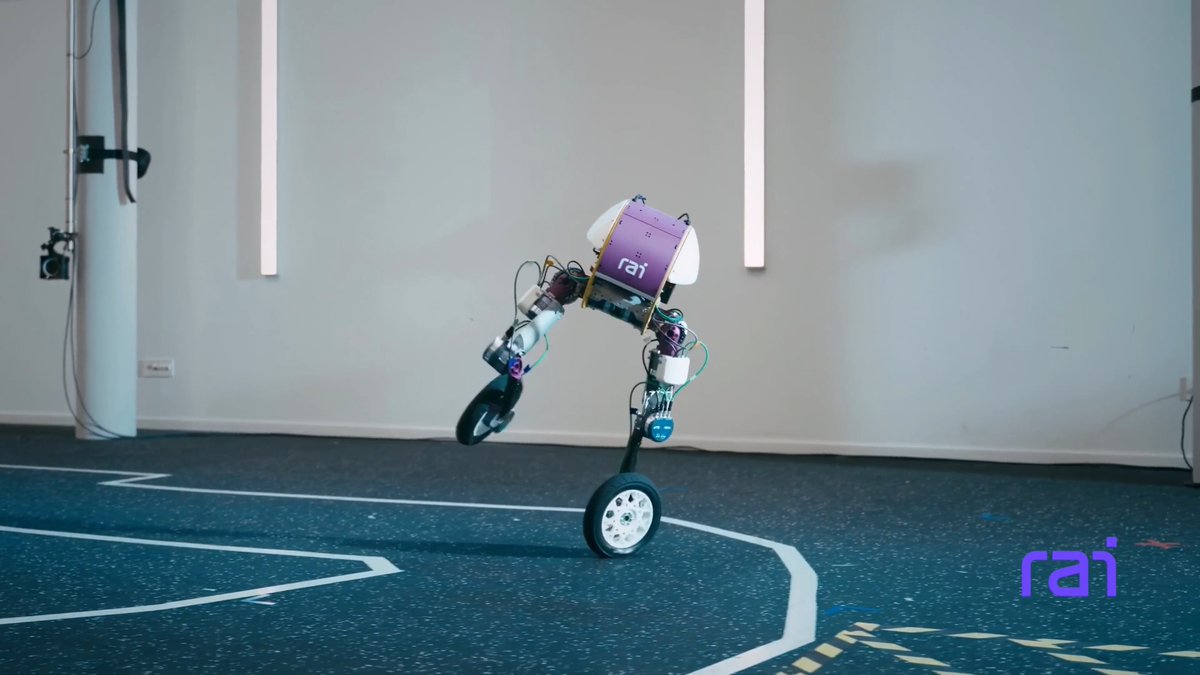
Happy #IROS2026! Stop by the RAI Institute booth #1102 to grab some stickers and check out some of our custom-built robots including the UMV, Roadrunner, and Koala grippers. You can also catch Roadrunner in action in the robot demo area. Check the Exhibit Hall demo schedule for more details!
RAI Institute42,229 görüntüleme • 20 gün önce
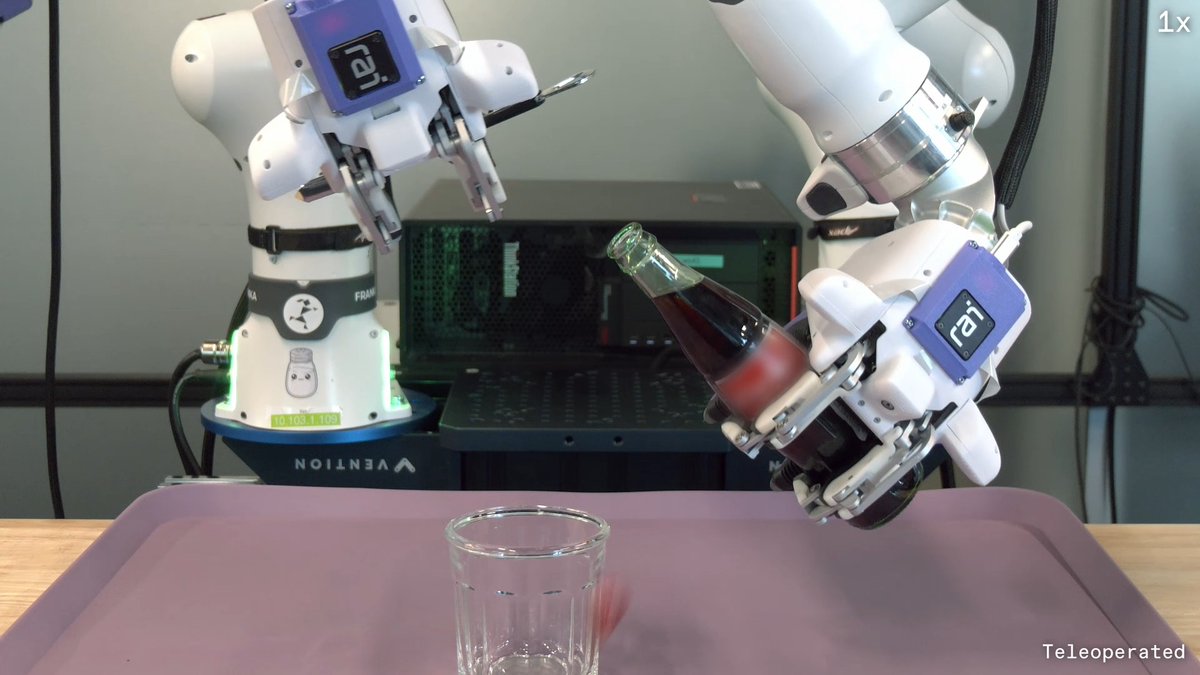
The Koala gripper is a co-designed system that pairs a handheld data collection device and a robotic gripper, allowing a single operator to easily record task demonstrations. Engineered with three controllable degrees of freedom and force-optimized triggers, the device enables complex, human-like object interactions. Training on a dataset of several hundred demonstrations has yielded successful policies, while unlocking capabilities outside the realm of parallel jaw grippers. By facilitating the transfer of intuitive human techniques to robotic platforms, the Koala gripper bridges the gap between human actions and autonomous dexterous manipulation. Learn more:
RAI Institute18,978 görüntüleme • 1 ay önce
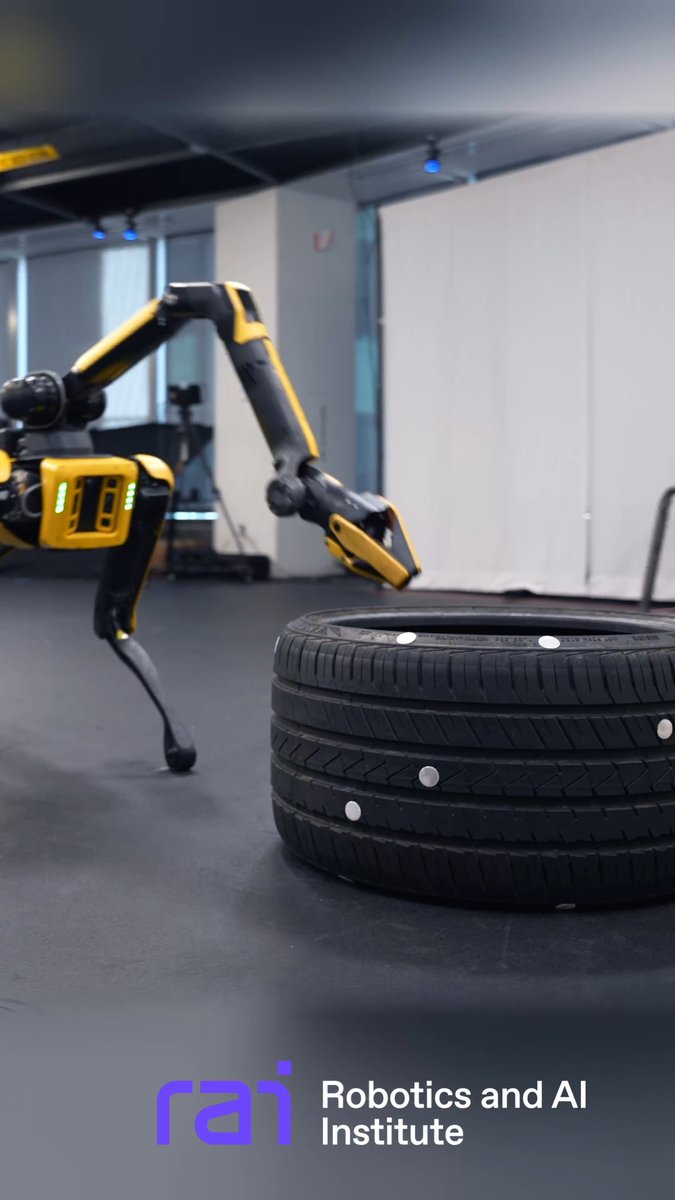
See Spot perform dynamic whole-body manipulation. Using a combination of reinforcement learning (RL) and sampling-based control, the robot is able to autonomously drag, roll, and stack tires weighing 15 kg (33 lb), well above its maximum arm lift capacity. Learn more about coordinating locomotion and manipulation processes:
RAI Institute87,753 görüntüleme • 1 yıl önce

Using reinforcement learning we have expanded the range of techniques the Ultra Mobile Vehicle (UMV) uses to handle terrain and obstacles, including hops, out-of-plane balance, and level-ground flips. Millions of physics-based simulations provide training data to support zero-shot transfers.
RAI Institute75,272 görüntüleme • 1 yıl önce


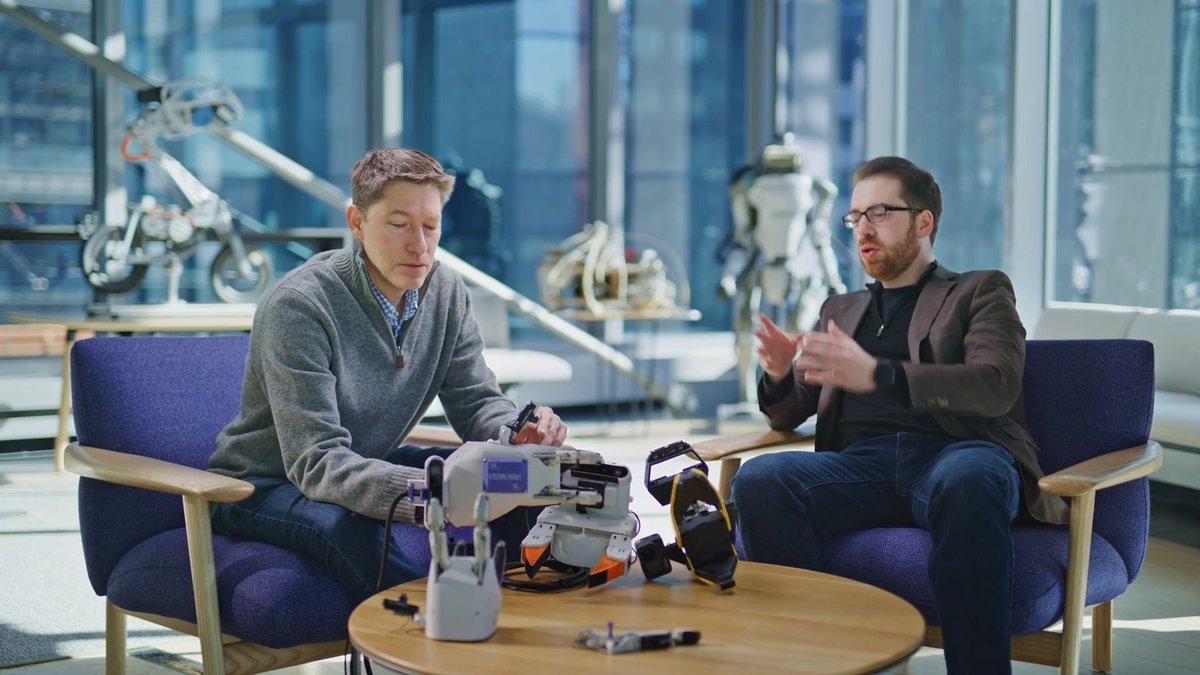
One approach to collecting data for contact-rich manipulation is handheld grippers. These devices let the operator feel contact with objects and the environment directly through the mechanism. To make sure the data collected transfers to the robot, we've co-designed handheld and robot grippers: same linkage mechanisms, same degrees of freedom, same force transmission. The Koala platform lets the human feel through the linkages what the robot will feel through its actuators. Watch to learn more about our gripper designs, data collection approach, and policy training:
RAI Institute23,538 görüntüleme • 5 ay önce
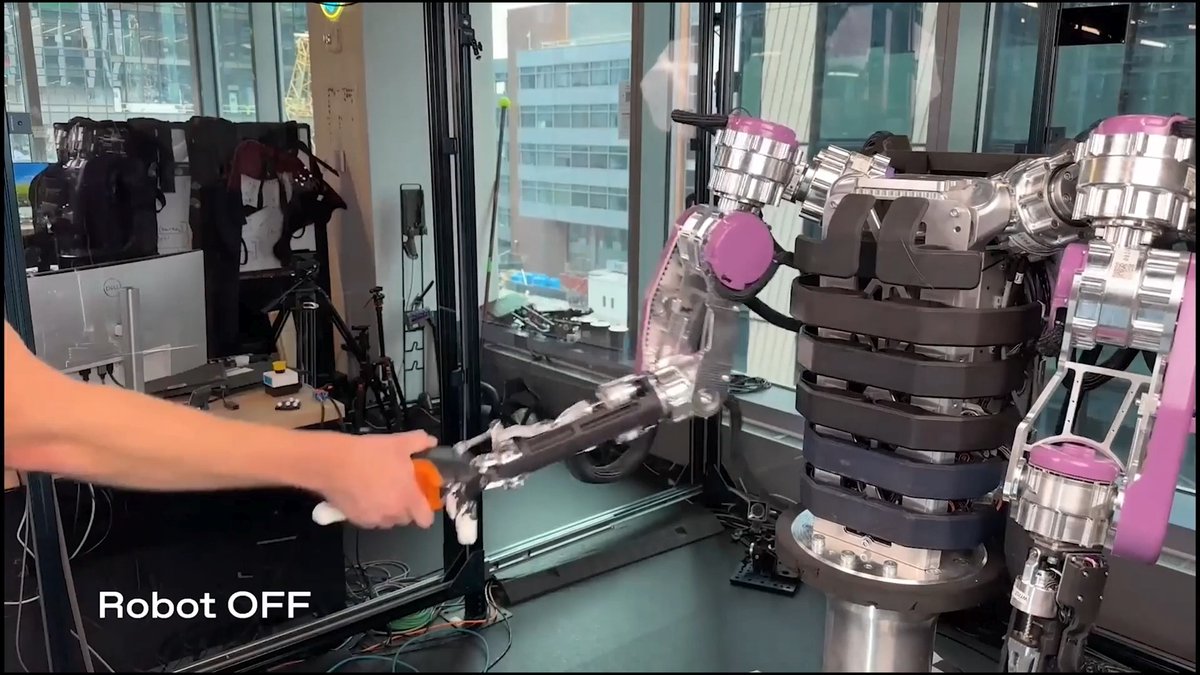
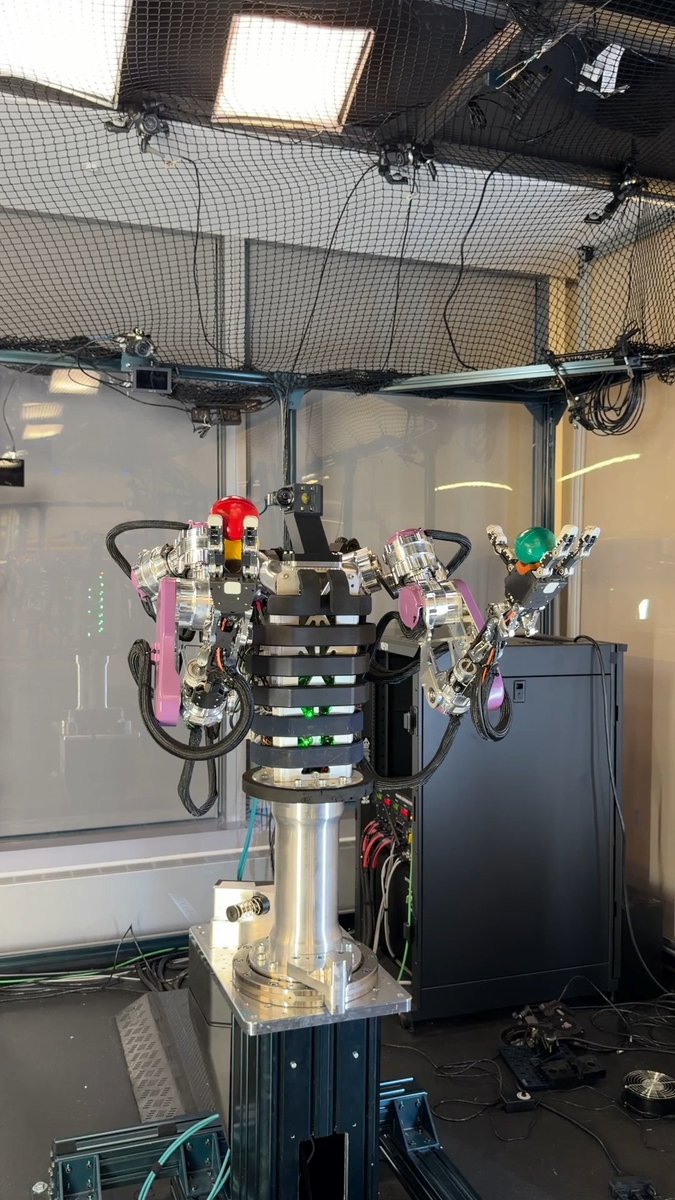
Happy #NationalRoboticsWeek! Last year, we gave you a sneak peek at AthenaZero, our robotic manipulator built to tackle dynamic tasks like a human arm. Learn more about how this fast, precise robot can switch in an instant from a gentle touch to high force depending on what the task requires:
RAI Institute23,736 görüntüleme • 6 ay önce
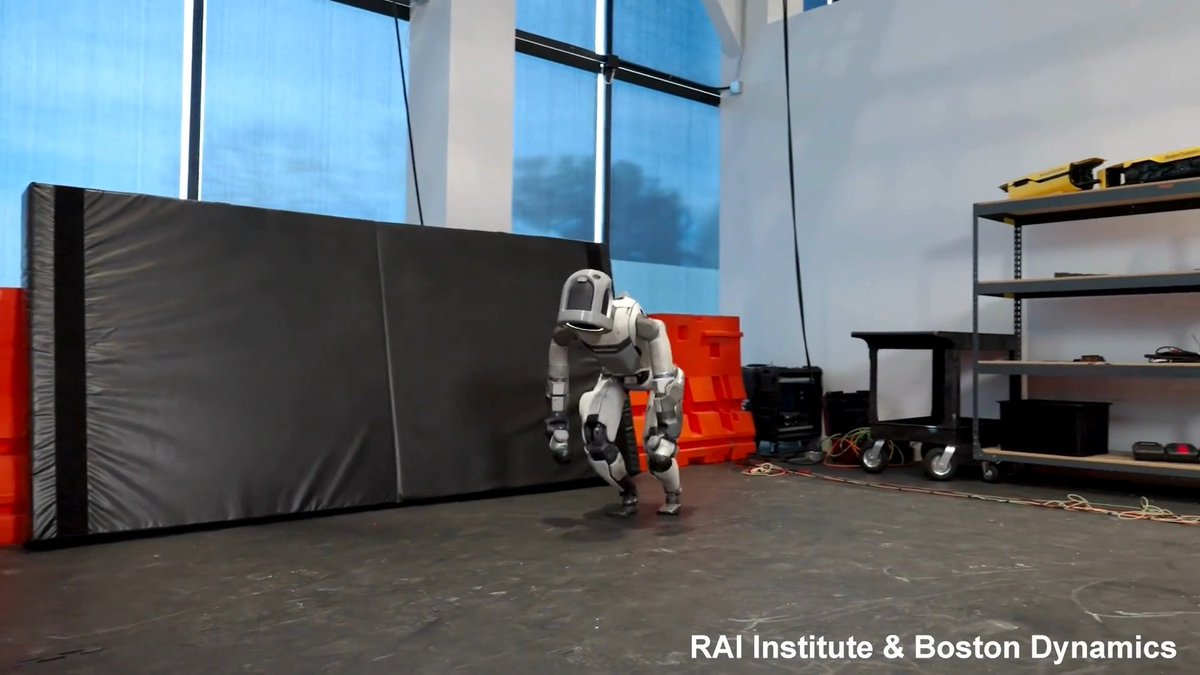
Atlas can perform a backflip combo like a gymnast and also walk naturally across a stage. These very different movements are enabled by the whole-body learning framework developed by the RAI Institute and deployed by Boston Dynamics. We’re getting closer to robust, generalist humanoid behaviors that transfer zero-shot from simulation to physical performance:
RAI Institute27,538 görüntüleme • 8 ay önce

Dynamic manipulation steps up to the plate! This is a first look at a low-impedance platform designed to study how robots manipulate objects. In this demo, two robots play catch and practice batting, even teaming up with humans. The robots are capable of throwing 70mph [112 kph] and can catch and bat at short distances (23ft [7m]) :
RAI Institute25,711 görüntüleme • 11 ay önce
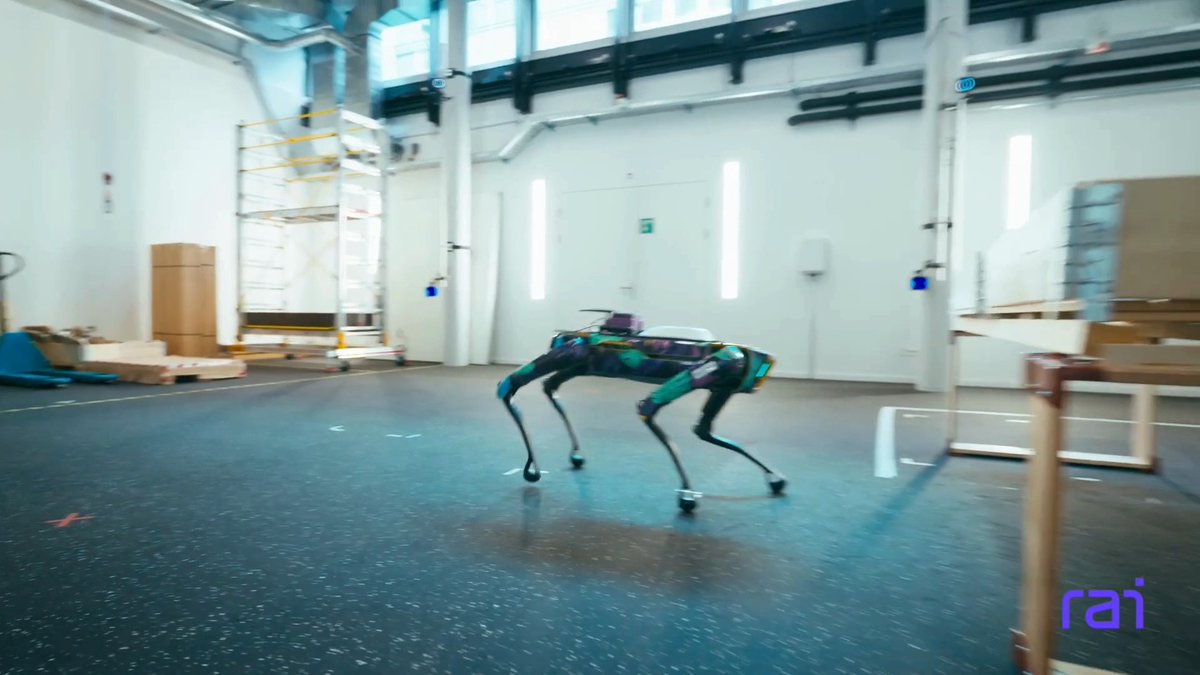
Watch Spot crouch, jump, climb boxes and leap across gaps, controlled by a neural network trained with reinforcement learning (RL) and multi-expert distillation. Multiple expert policies were trained and distilled together into a single policy that was fine tuned to improve performance over diverse terrains. This work was inspired by ANYmal’s parkour capabilities. The neural network processes depth data from Spot's sensors to construct an understanding of the environment.
RAI Institute15,057 görüntüleme • 5 ay önce

Researchers from RAI Institute present Diffuse-CLoC, a new control policy that fuses kinematic motion diffusion models with physics-based control to produce motions that are both physically realistic and precisely controllable. This breakthrough moves us closer to developing generalist policies that enable humanoid robots to perform diverse tasks, including dynamic locomotion and contact-rich manipulation, in a natural-looking and robust way. Learn more at
RAI Institute13,580 görüntüleme • 1 yıl önce
Daha fazla içerik yok.