正在加载视频...
视频加载失败
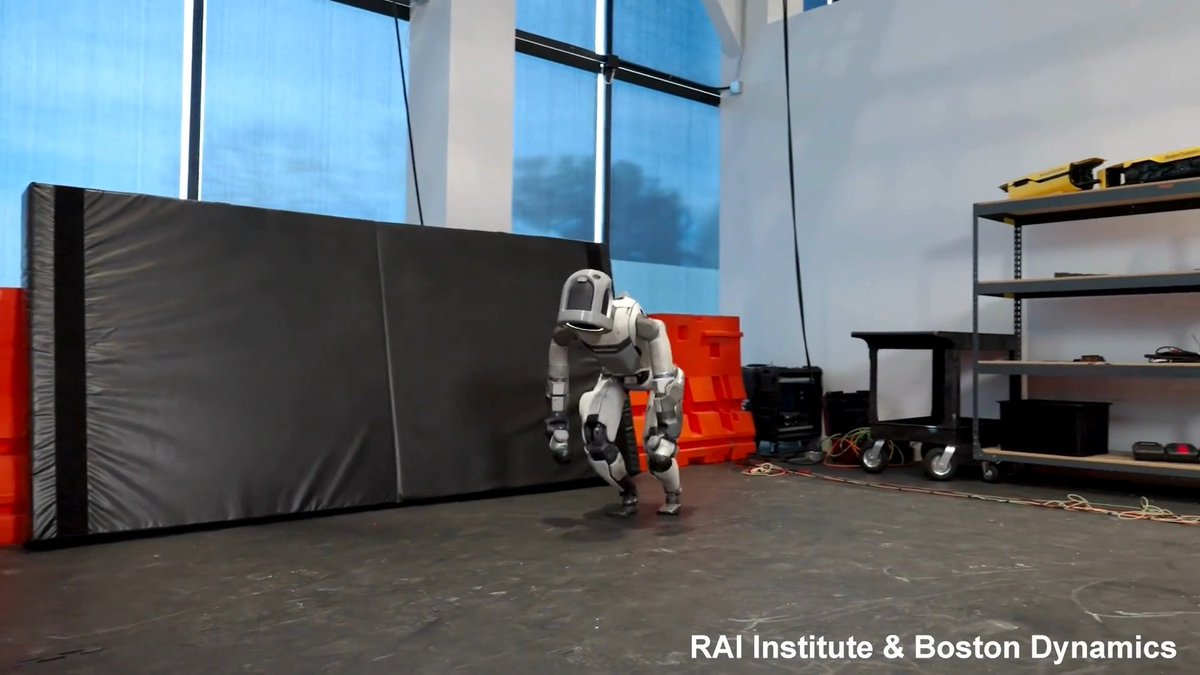
Researchers from RAI Institute present Diffuse-CLoC, a new control policy that fuses kinematic motion diffusion models with physics-based control to produce motions that are both physically realistic and precisely controllable. This breakthrough moves us closer to developing generalist policies that enable humanoid robots to perform diverse tasks, including dynamic... show more
13,560 次观看 • 1 年前 •via X (Twitter)
2 条评论

Oliver S1 年前
Beeindruckend, wie diese Forschung Steuerbarkeit und Realismus vereint. Ein echter Meilenstein für präzise Roboterbewegungen!

Wendy Carlosa1 年前
so the word algorithm is played i guess. guess we'll do a century worth of policy try to do better logos I don't want the year 2100 looking like times square helvetica got into rap.