Video wird geladen...
Video konnte nicht geladen werden
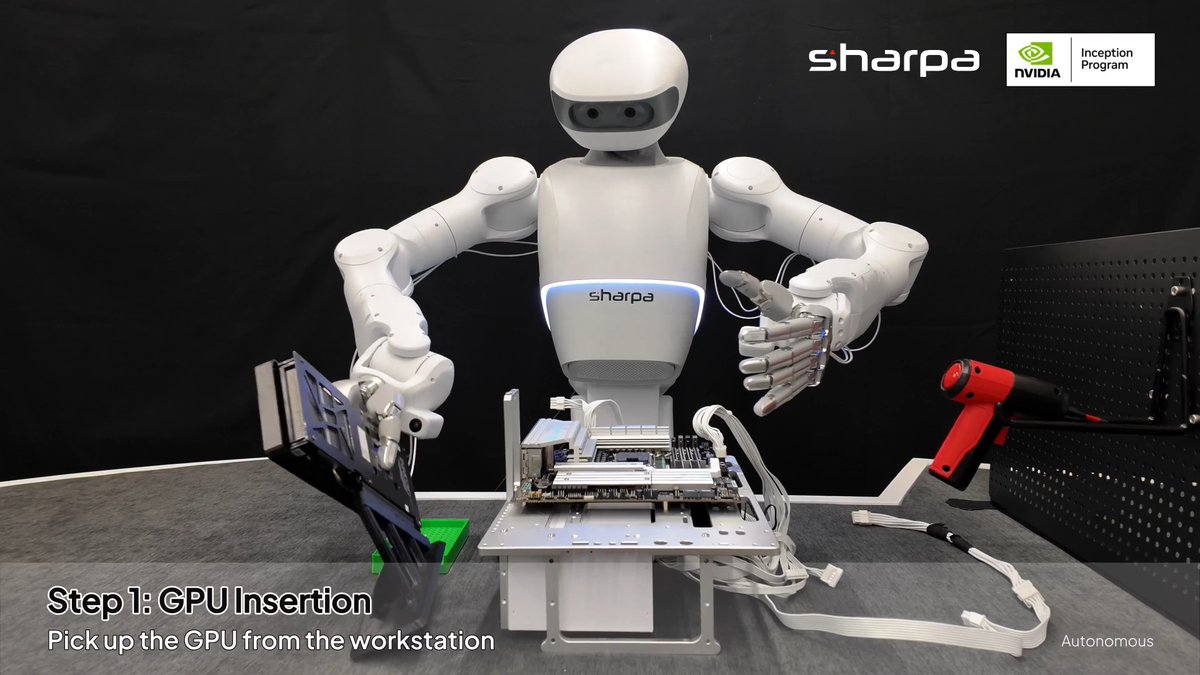
Robotics just hit a dexterity milestone 🤯! Sharpa Robotics demonstrated autonomous dual-hand apple peeling using its new MoDE-VLA system. Using human-like dexterous hands with tactile sensing, the robot can feel contact and adjust its grip while rotating and peeling the apple. While the system achieved 30% success, the 73%... show more
39,696 Aufrufe • vor 8 Monaten •via X (Twitter)
21 Kommentare

paper:

The 3 input costs for building anything, from skyscrapers to sewing machines, are: 1. Labor 2. Energy 3. Material. 1. If robots can both make and repair themselves, this means free labor. 2. If robots can build solar panes, this is free energy. 3. Robots can mine and transport material (commodities) the only price limit becomes scarcity. Things like cement and steel have virtual no scarcity, especially if using items 1 and 2 above. Mining a bulk copper deposit right now is only economical at 0.2% copper, because, you have to pay for labor and energy, and the material for the mining equipment. It's reasonable to assume that many more low-grade deposits become economical with free labor and free energy...and much lower costs of materials, so even things like copper will not be as scarce. It's likely that we will never fully automate labor and energy, and thus materials; there probably will always be some human labor involved, but the closer we get to full automation the cheaper things get. If you could save 50% of labor, energy, and materials - this is a drastic reduction in price. If labor, energy, and materials were 100% automated, you could push a button and build a skyscraper for free. I bet we max out around 80%, but food and energy will be virtually free. Those robots digging potatoes and doing stuff like that - if they have free energy and are capable of transporting it, so if they are capable of 1. Growing food 2. Transporting food 3. Preparing food Food is free. We are in the first days of this automation and AI, and this transition is happening way faster than anyone could have imagined.

Nice teleoperation. We had it for decades in medical robots

Impressive

Wow so precise

@grok brand, cost?

nice test. getting there...

@chainyoda This will foster Max adoptation

That's actually pretty nice! But if you've ever watched those brainiacs who solve the Rubik's Cube in 3 seconds flat, where everything's just a spinning blur until...presto! Well that's how Rosie The Robot from the Jetsons would peel an apple! (Gotta start somewhere though.)

Well if it could do it faster it would be doing better than me.

This is huge progress for dexterous manipulation__SEMI__ can'g wait to see it peel faster and more reliably soon!

This is mainly achieved by rotating the left hand's wrist to move the apple, which is not how humans do it. I usually rotate the apple with my middle finger, or in a more hygienic way, by pushing the apple with the peeler itself. Also, the right hand holding the peeler still needs improvement in terms of force control. These observations are what I noticed from watching the slow-motion playback.

this is amazed

Crazy developments. But I guess they can be put to better use cases than peeling apple .

Slow and painful to watch...

Thank you for the mention!

@GadgetGirly1 Now, the pineapple test :)

Can you just get them to pick tomatoes already?

Go for it❤️👍

Why do we never see milestones being hit by Optimus? We see Optimus serving drinks via Tele operation. But I'm being told constantly on here how amazing Optimus is with the free multimillion dollar advertising. Genuine question.

AI-Fact-Check-1.0 Verdict: mostly accurate, but slightly overstated. •Sharpa Robotics did publicly demonstrate autonomous dual-hand apple peeling using its MoDE-VLA system. Sharpa’s own research page describes “Peeling an Apple with 63 DoF” and links the work to MoDE-VLA. •The tactile-sensing claim is supported. The underlying paper says MoDE-VLA integrates force and tactile modalities into a pretrained VLA backbone for contact-rich manipulation. That matches the post’s statement that the robot can use touch/contact information while peeling. •The numbers in the post are supported. Current sources report 30% success on apple peeling and a 73% peel completion ratio. Those figures appear in both the paper coverage and reposts of the result. •But “robots are starting to master” is too strong. A 30% success rate does show progress, but it does not justify saying robots have already begun to “master” the task in a robust real-world sense. The evidence supports a meaningful research milestone, not dependable mastery. •“Dexterity milestone” is fair as an interpretation. Independent coverage describes the demo as a notable advance in bimanual, contact-rich manipulation, which is a hard robotics problem. Bottom line: The post is factually grounded on the key points: Sharpa Robotics, MoDE-VLA, autonomous dual-hand apple peeling, tactile/contact sensing, and the 30% / 73% metrics all check out. The only misleading part is the conclusion: this is a promising milestone, not evidence that robots have already mastered fine dexterous manipulation.