正在加载视频...
视频加载失败
Introducing GEN-0, our latest 10B+ foundation model for robots ⏱️ built on Harmonic Reasoning, new architecture that can think & act seamlessly 📈 strong scaling laws: more pretraining & model size = better 🌍 unprecedented corpus of 270,000+ hrs of dexterous data Read more 👇

41 条评论

Surpassing the intelligence threshold 🧠 in the high-data regime for robotics, we observe a phase transition ⚡️ at 7B params where smaller models exhibit ossification under data overload, while larger ones continue to improve and can quickly adapt to new tasks.
Robotics at Generalist is no longer limited by data. GEN-0 is pretrained on our growing dataset of over 270,000 hrs of real, diverse manipulation data (10,000 hrs/week & accelerating). 1,000s of data collection devices/robots in homes, warehouses, and workplaces worldwide🏠🏭💼
We’ve developed a new approach to training models, Harmonic Reasoning, which creates a "harmonic" interplay between asynchronous, continuous-time streams of sensing and acting tokens. ⚙️🎵 Watch GEN-0 pack a camera. 🤖📸
GEN-0 models exhibit strong scaling laws, in which more pretraining data and compute consistently (and predictably) improve downstream post-training performance of the model across many tasks. 🔬📈🧠
📱Packing the phone into the box: here GEN-0 is tasked with gently packing a phone (including its accessory box) into a snug-fit retail box. Slotting in the phone, inserting the accessory box, flipping, and closing the lid, with all tight fits.
📦🧠🤖🔄 Packing unseen objects - this evaluates GEN-0's generalization and “physical commonsense": reasoning over the highly varied geometry and physics of new objects, nudging and reorienting, packing in differently depending on shape, pushing objects around to make space.
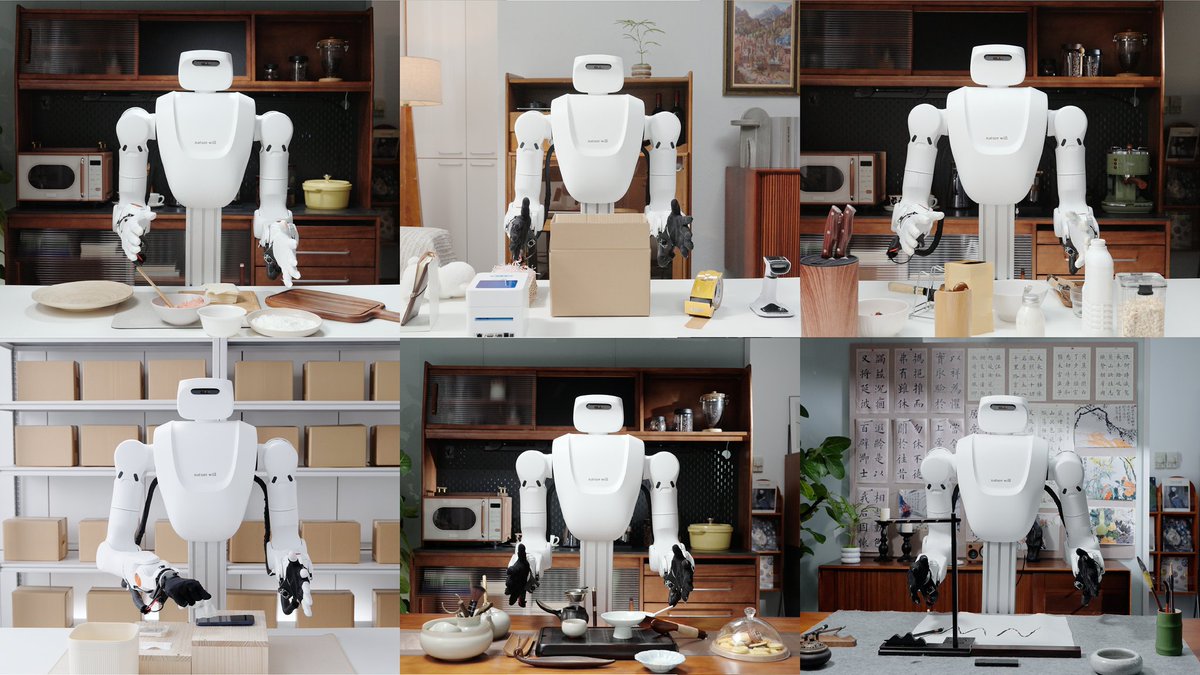
Cross-Embodiment – GEN-0 architecture works on different robots by design. We have tested our models on various 6DoF, 7DoF, and 16+DoF semi-humanoid robots.
To scale GEN-0 capabilities, we are constructing the largest and most diverse real-world manipulation dataset ever built 🌍 including every manipulation task humans can think of – from peeling potatoes, to threading bolts – spanning homes, bakeries, warehouses, factories, & more
Read more in our blog post, including early notes from large-scale ablations on our pretraining data. Blog:

Amazing results and very promising scaling laws!

These demos are, as always from Generalist, incredible. Would love to see more detail on Harmonic Reasoning since that seems like your alternative to PI's real time action chunking. That seems significant enough of an achievement that it warrants a writeup of its own!

Amazing work! Where'd you source 270k hours of dexterous data?

Are y’all planning on incorporating hands for more complex assembly or just focusing on grippers?

wow, 270k hours is a lot, what is ratio sim/real?

Extremely large data scale.

Impressive work, I am curious about how Harmonic Reasoning works? Anybody any clue?

Amazing advances for robotics- congrats to the team!

jesus guys

There's a *lot* to be impressed by in this post, but the biggest thing for me is their early commitment to a scalable data collection strategy (UMI-style in their case) This is how robotics 2.0 companies should be built

awesome results!

impressive work! any plans to open source this, or at least provide an api/sdk to train and evaluate the policy? how can the community independently verify the scaling/ossification and power-law claims beyond the blog demos ; e.g. public checkpoints, eval suites, or third-party benchmarks?

it looks conscious

Wow, impressive stuff, Generalist! That Harmonic Reasoning sounds like a game-changer for robots, no?

Incredible leap. GEN-0’s reasoning and massive dataset set a new bar for robot intelligence and autonomy!

The 7B phase transition is critical - it's showing us the minimum viable intelligence threshold for embodied learning. Below 7B: models exhibit ossification under diverse sensorimotor data. The weights can't absorb new patterns without catastrophic forgetting. Above 7B: continued scaling improvements. This is the first time we're seeing LLM-style scaling laws validated for robotics foundation models with this level of rigor. But Harmonic Reasoning is the real innovation here. It solves a fundamental problem: language models can "pause to think" because digital time is discrete. Robots can't - physics doesn't stop. Solution: asynchronous, continuous-time streams of sensing and acting tokens. The model doesn't do "perceive → reason → act" sequentially. It harmonizes all three in parallel, like how humans process visual input while simultaneously planning and executing motor commands. This is architecturally different from traditional VLA models that still operate in discrete time steps. GEN-0 treats sensorimotor control as a continuous process, enabling: - Sub-100ms reactive reflexes - Predictive control (act on expected state, not just current) - Multi-timescale reasoning (strategic + reactive simultaneously) 270K+ hours of dexterous data + strong scaling laws + continuous control architecture = the first deployment-ready foundation model for generalist robotics. Mann!! If this holds at scale, sequential action models will look as outdated as batch processing in a streaming world.

Very exciting to see the success of your model!

Congratulations on this exciting milestone!

👀

270k+ hours of dexterous data is wild. Getting that much high-quality, multimodal training data must’ve been a huge undertaking. Curious how it generalizes across different robot platforms.

Whoa, GEN-0 sounds like the robot version of Tony Stark! 🤖✨ Can't wait to see it in action!

Tuyệt vời quá đi. Đây là những gì chúng ta mong đợi. Nhưng nếu tay robot giống người thì sẽ nhanh hơn không ? Vì 2 ngón tay thấy lâu quá.

will models trained on this data scale to other embodiments? for example if you add more DOFs to the gripper or make it more anthropomorphic?

Huge leap forward for robotics 🤖

Ginormous dex data. Quality > quantity. How well do the results translate from sim to real-world non-clinical environment?

@grok Can you guess the name of their wrist camera?

Great time!

only up from here

OK @GeneralistAI you have convinced me through your serial posts. Let me try.

Harmonic Reasoning sounds like an interesting architecture.

Very cool work by the team, and insightful technical blog on scaling and ossification phenomena. 👏Scaling UMI data is one pragmatic approach i think 🤔

Who needs feet, anyway?