Video yükleniyor...
Video Yüklenemedi
Two years ago, we released Genesis, a universal physics engine for robotics. Today, I’m excited to announce 🍎 Eden — a robot learning framework built from the ground up for agents, unleashing full potential of Genesis. One task definition. From simulation to real robots. Sim-to-sim and sim-to-real just got... show more

111,535 görüntüleme • 2 gün önce •via X (Twitter)
50 Yorum

Eden is built for coding agents: strict typed configs and errors that name the fix. We timed Claude Opus 5 building new tasks (scene included) until it had a working policy (mean of 5 runs): Door opening: 2.1× faster than Isaac Lab Bin picking: 4.0× Deformable cutting: 1.6× 2/11
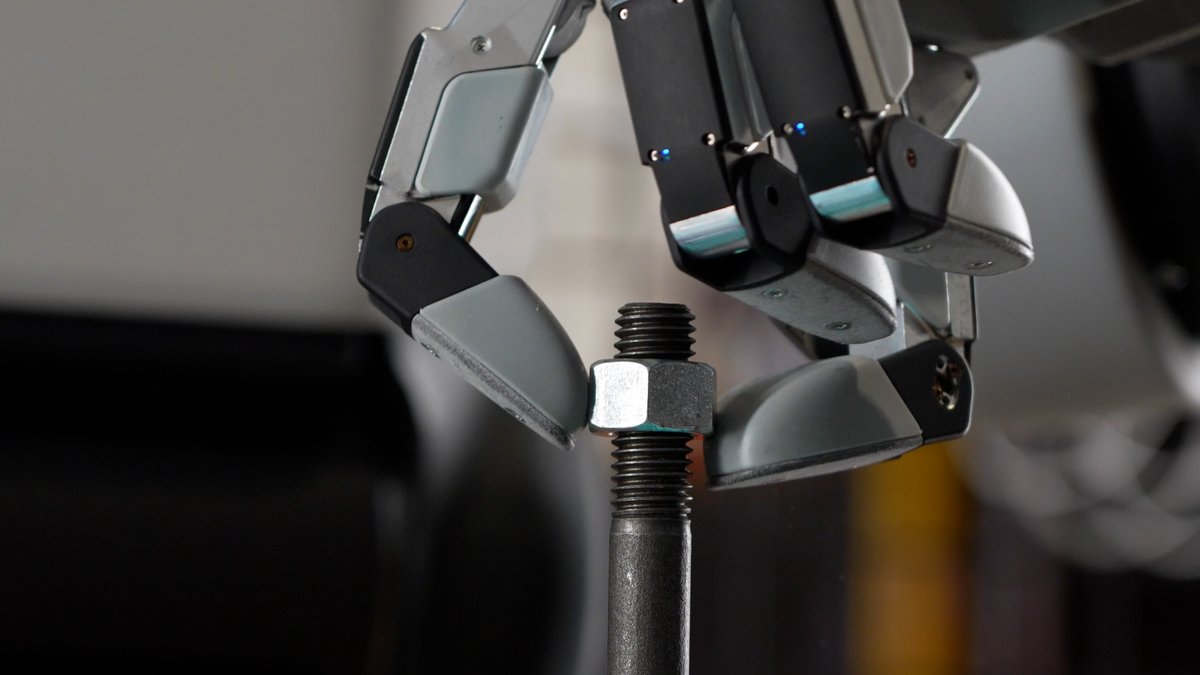
Sim-to-sim and sim-to-real just got easier. From a config, train, validate, and deploy: eden train — thousands of parallel environments in Genesis eden deploy --mujoco — sim-to-sim validation eden deploy — the real robot Left: MuJoCo (sim2sim) Right: hardware (sim2real) 3/11
66 tasks. 245 composable MDP terms. Thousands of envs per GPU, multi-GPU with DDP. Bring your trainer: rsl_rl, rl_games, skrl, Stable-Baselines3. Bring your benchmark: LIBERO, robosuite, SIMPLER, PolaRiS, and more — already ported. eden train --task <task> 4/11
47 robots and 11 composite rigs out of the box: humanoids, quadrupeds, arms, and dexterous hands. Easy to add your own. G1, Oli, Go2, Franka, UR5e, xArm7, iiwa14, WidowX, YAM, LEAP, Inspire, XHand, Wuji, Sharpa… Plus 950+ objects to put in front of them. 5/11
21 published policies run as shipped. SONIC, BeyondMimic, TWIST2, HOMIE, AMO, ProtoMotions, MetaMotivo, π0.5, GR00T, Octo… Run them out of the box to try, supervise, or generate data: eden inference --policy <policy name> --vis 6/11
Human motion in, robot motion out. Loaders for 12+ motion datasets in one format (AMASS, LAFAN1, OMOMO, ARCTIC, DexYCB…), video-to-motion with GVHMR, and retargeting onto any humanoid or hand — objects included. eden retarget 7/11
Not just rigid bodies. Every Genesis solver, plus custom solvers including Mochi — one solver that couples rigid, cloth, soft-body, and rod dynamics. Two arms fold a towel. A trained policy wipes a bar with a foam sponge. A cable gets routed into a port. A G1 fills a glass at the tap. 8/11
Sensors and rendering that keep up with the sim. RGB-D, lidar, tactile, IMU, audio, and more. Batched Gaussian-splat scenes across environments. Path tracing with Nyx. Here: a Go2 scanning a tunnel with lidar, and 16 splat environments rendered in batch. 9/11
And some tasks are just fun. 森羅万象 brushed in kaisho with a modeled Chinese brush. The Starry Night in wet acrylic, paint blending as it goes. Chopin on the piano, with sound synthesized from the pressed keys. Sound on 🔊 10/11
Eden is open source (Apache-2.0) and on PyPI. ⭐ 📖 pip install eden-world Star, fork, and explore! What should we build next??

Assuming this works on AMD just like genesis does 😁?
Mostly yes, we still need to optimize the performance for AMD with Genesis though 💪
👏🏻🔥🔥

Eden looks really clean. Building it agent first on top of Genesis with those speedups and a straightforward sim to real path is a smart move. Congrats.
Thank you!!

congrats on the release Kashu! long time coming!
Thank you Alex! It took me two years to build something really useful

Any drones in the 47 robots? That's the one I'd want to try sim-to-real on.
I can add to my TODOs! Please star the repo and stay tuned!
Done

Huge milestone! Sim-to-real has always been the hardest part of robotics. Can't wait to try Eden with Genesis! 🤖🚀 #Robotics

@DanielXieee impressive!
@DanielXieee Thank you!!

less glue code between stacks, finally
Yesss!

Congrats on the launch! Excited to see what people build with Eden 🚀
Thanks! 🚀

nice! hany plan to support direct env?
Currently not, it’s better to unify the environment definition not to confuse agents/coders. Also managers are easier to maintain as a framework.

Keeping the task definition consistent makes comparisons easier to set up. Gonna watch is how much tuning the real robot still needs once it leaves simulation.

Batched splat scenes across envs is the part I'd try first. Has a detector or vision policy trained only on those renders held up on a real camera, or do you still need a slice of real images in the mix?
As far as we tested to fine tune a VLA with data collected in Eden, sim data alone worked fine. But I think this also depends on the task setups so let me know what you observe!

Agent-first is the right call. Building agent tooling for Isaac Lab, our hardest problem wasn't launching runs, it was agents trusting reward curves: reward climbed while pose error barely moved. Does Eden hand agents task success metrics and crash/stall signals by default?

We hit latency walls trying to sync sim state with onchain verification for our agents.

通用物理引擎的价值,要等它跑在别人家的硬件上也成立,才算真的通用。

With 21 policies that can generate data out of the box, this is a nice setup for asking which generated episodes actually move success rate and which just add volume. Have you looked at that yet?

exciting news! I want to feature you guys on our YT channel. Are you interested in it?

agents build the task 1.6–4× faster in isaac lab. does that speed hold once the sim-to-real gap shows up on the real robot

Are you planning on supporting Newton?

Frameworks now brag about how fast agents use them, not humans. Docs for devs are becoming the legacy format.

@AkariAsai How does genesis compare to newton? do you plans to support newton too?

Timing all the way to a working policy is more informative than timing code generation alone. In the five-run comparison, was most of the speedup from getting the first task definition right, or from needing fewer debug-and-retrain cycles?

What tends to break first when an Eden task moves from sim onto a real robot?
I think most of the failures can be flagged by sim2sim but we want to make sure the real robot starts with the same pose as in sim2sim setup, otherwise hard to catch

Congrats @kashu_yamazaki looks very useful, can someone bring their own simulator as well?
Thank you Erwin. Currently I only support Genesis (besides Mujoco for sim2sim; this is more like a deployment backend) mainly for the maintenance burden. So maybe it’s not very straightforward at this moment. What I plant to do is to port the solvers to Genesis as addons (like we did for Mochi) and cover wide range of phenomena through this.
I will give it a try, does it rely on differentiability at all (most likely not for RL right) or mainly blazing fast parallel simulation?
I plan to include dedicated support for diff sim in the next release.
shac style or SuperMimic style? with SuperMimic any physics engine becomes differentiable.
I am looking if we can do that with explicit diff sim!